Home › Audio / Visual / Telematics › PARK ASSIST / MONITORING › TOYOTA PARKING ASSIST-SENSOR SYSTEM
RM19Y0E _56 Audio / Visual / Telematics _003001 PARK ASSIST / MONITORING _0015174 TOYOTA PARKING ASSIST-SENSOR SYSTEM D

PARK ASSIST / MONITORING  TOYOTA PARKING ASSIST-SENSOR SYSTEM  OPERATION CHECK  


CHECK INITIAL CHECK FUNCTION

E238941
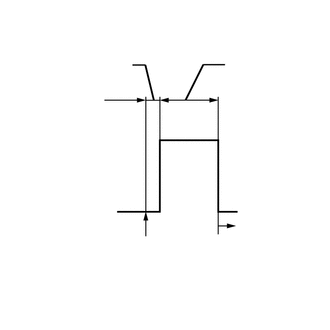
2.396,0.604 3.094,1.365 0.698,0.76 10 0.5 to 1.3 seconds 0.073,0.146 1.604,0.813 1.531,0.667 12 Buzzer Sound: 0.271,0.604 1.26,1.5 0.99,0.896 9 Approximately 0.3 seconds 2.531,2.042 3.198,3.302 0.667,1.26 9 Detection Operation Starts 0.844,1.385 1.396,1.896 0.552,0.51 10 ON 0.844,2.115 1.427,2.531 0.583,0.417 10 OFF 0.802,2.521 2.302,3.063 1.5,0.542 9 - Ignition Switch ON 0.802,2.844 2.469,3.365 1.667,0.521 9 - Shift Position is R

a.

Check the initial check function for the buzzer and sensor.

i.

When the ignition switch is on and the shift lever in R, check that the following occurs: 1) after 0.3 seconds, the buzzer sounds for approximately 0.5 to 1.3 seconds, and 2) the system starts the obstacle detection operation.


MALFUNCTION BUZZER


a.

Ultrasonic sensor open circuit.

i.

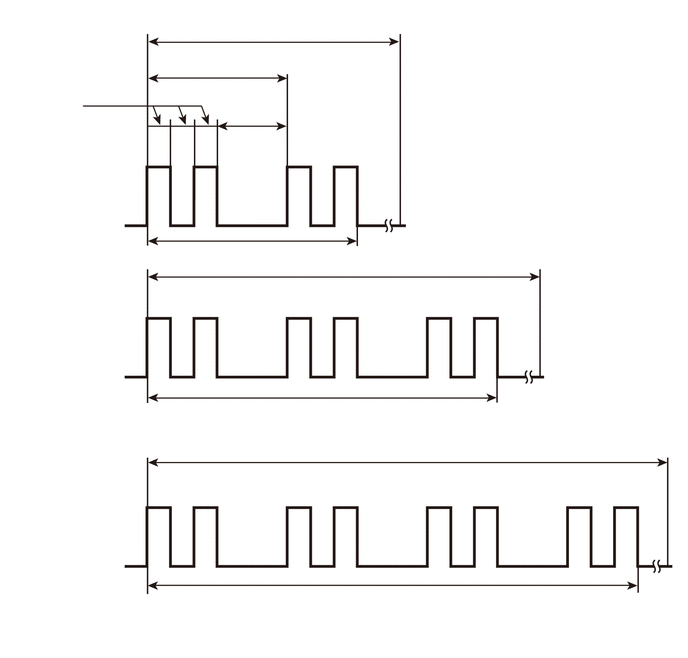
If there is an open circuit between the No. 1 ultrasonic sensor and the clearance warning ECU assembly or if a sensor is malfunctioning, the malfunction is indicated as shown in the illustration.
E261811
3.771,6.135 4.969,6.531 1.198,0.396 10 5.25 sec. 3.76,4.854 5.25,5.375 1.49,0.521 10 6.0 sec.(4 cycles) 2.448,2.542 3.646,2.938 1.198,0.396 10 2.25 sec. 2.333,1.365 2.979,2.208 0.646,0.844 10 0.75 +/- 0.15 sec. 1.719,0.844 3.177,1.375 1.458,0.531 10 1.5 sec.(1 cycles) 2.271,0.458 3.677,0.99 1.406,0.531 10 3.0 sec.(2 cycles) 3.104,4.198 4.302,4.594 1.198,0.396 10 3.75 sec. 3.01,2.927 4.5,3.448 1.49,0.521 10 4.5 sec.(3 cycles) 0.219,1.021 0.865,1.865 0.646,0.844 10 0.25 +/- 0.05 sec. 0.135,1.938 0.979,2.938 0.844,1 10 Sensor RH and Buzzer 0.969,1.656 1.594,2.01 0.625,0.354 10 ON 0.969,2.26 1.594,2.615 0.625,0.354 10 OFF 0.979,3.25 1.604,3.604 0.625,0.354 10 ON 0.99,5.208 1.615,5.563 0.625,0.354 10 ON 0.979,3.844 1.604,4.198 0.625,0.354 10 OFF 0.99,5.813 1.615,6.167 0.625,0.354 10 OFF 0.125,3.469 0.969,4.469 0.844,1 10 Sensor LH and Buzzer 0.063,5.469 0.99,6.458 0.927,0.99 10 Sensor RH/LH and Buzzer

HINT:
·

The example shows an open circuit in the No. 1 ultrasonic sensor.

·

If a sensor has an open circuit, a warning indication will be displayed and the buzzer will beep. In such a case, perform inspection according to the Problem Symptoms Table.


DETECTION RANGE MEASUREMENT AND DISPLAY INSPECTION


NOTICE:

Make sure that the parking brake is firmly applied to prevent the vehicle from moving.


a.

Turn the ignition switch to ON.


b.

Move the shift lever in R to check the sensors.


c.

Move a pole around the sensor to measure the detection range of the sensor.

NOTICE:
·

These detection ranges are applicable when positioning a pole with a diameter of φ60 mm (2.36 in.) parallel or perpendicular to the ground.

·

The ranges vary depending on the measuring method and type of obstacle (such as walls).


i.

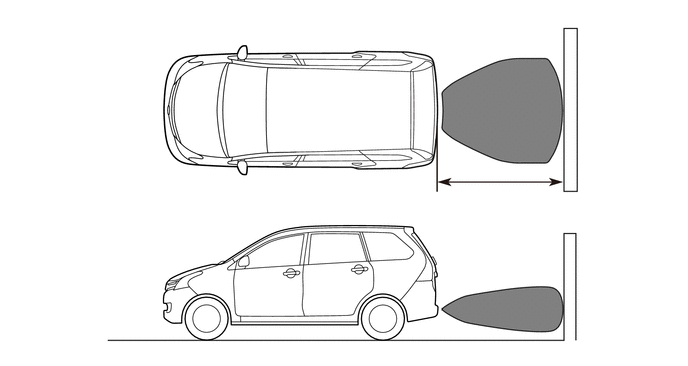
Back sonar sensor detection range.

Y127228
5.125,1.948 5.604,2.302 0.479,0.354 10 *1
*1 Approximately 1500 mm (59.1 in.) - -


d.

When the ultrasonic sensors have detected an obstacle, check that the buzzer sounds and indicator blinks.

Operation condition:
Shift Position Buzzer Detection Vehicle Speed
Back LH
Back RH
R Sounds -


e.

Check that the buzzer sounds and indicator blinks.

HINT:
·

Buzzer sound and indicator operation will operate together.

·

The indicator blinks or illuminates when its related sensor detects an obstacle.


E200027
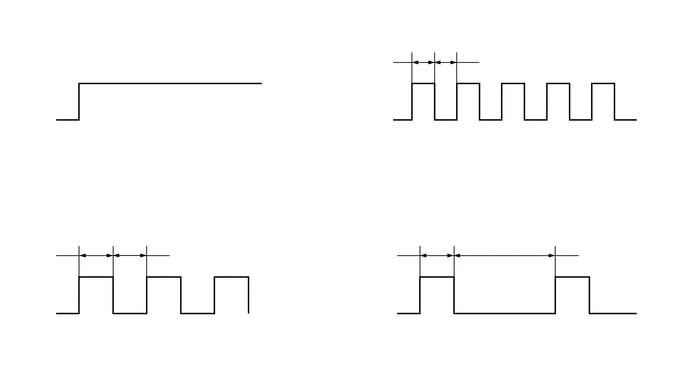
5.083,0.333 4.406,0.333 4.406,0.333 4.406,0.635 false 4.656,0.635 4.656,0.333 false 1.688,2.354 1.01,2.354 1.01,2.354 1.01,2.656 false 5.729,2.344 5.052,2.344 5.052,2.344 5.052,2.646 false 4.208,2.344 4.563,2.344 4.563,2.344 4.563,2.646 false 1.354,2.656 1.354,2.354 false 0.125,0.219 0.615,0.604 0.49,0.385 10 *1 3.74,0.219 4.125,0.594 0.385,0.375 10 *2 0.125,1.99 0.531,2.354 0.406,0.365 10 *3 3.74,1.99 3.979,2.188 0.24,0.198 10 *4 5.177,0.26 6.406,0.792 1.229,0.531 10 75 +/- 7.5 msec. 1.729,2.271 3.125,2.75 1.396,0.479 10 150 +/- 15 msec. 3.135,2.271 4.375,2.667 1.24,0.396 10 150 +/- 15 msec. 5.802,2.271 7.094,2.802 1.292,0.531 10 650 +/- 65 msec. 0.177,1.156 0.802,1.552 0.625,0.396 10 OFF 0.177,0.771 0.823,1.177 0.646,0.406 10 ON 3.667,1.156 4.188,1.5 0.521,0.344 10 OFF 3.667,0.771 4.323,1.188 0.656,0.417 10 ON 0.177,3.198 0.656,3.5 0.479,0.302 10 OFF 0.177,2.802 0.708,3.135 0.531,0.333 10 ON 3.667,3.198 4.271,3.521 0.604,0.323 10 OFF 3.667,2.802 4.24,3.146 0.573,0.344 10 ON
*1 Close-range Detection *2 Medium-range Detection
*3 Long-range Detection *4 Maximum Long-range Detection


Back Sonar Sensor Detection Range:
Detection Distance
Close-range detection Within 350 +/-50 mm (13.7 +/-1.96 in.)
Medium-range detection 350 +/-50 to 450 +/-100 mm (13.7 +/-1.96 to 17.7 +/-3.93 in.)
Long-range detection 450 +/-100 to 600 +/-100 mm (17.7 +/-3.93 to 23.6 +/-3.93 in.)
Maximum long-range detection 600 +/-100 to 1500 +/-150 mm (23.6 +/-3.93 to 59.05+/-5.9 in.)


HINT:

Ultrasonic waves are used to measure the detection range. However, the detection range may vary depending on the ambient temperature.