CRUISE CONTROL LANE TRACING ASSIST SYSTEM DETAILS FORWARD RECOGNITION CAMERA
CONSTRUCTION
The forward recognition camera captures a view of the road up to approximately 50 m (164 ft.) ahead of the forward recognition camera.
The forward recognition camera detects lane markers and calculates the radius to the center of the lane, the vehicle center position disparity among the distances from each left and right lane marker and the angle disparity between the vehicle traveling direction and each left and right lane marker.
When one of the following operations is conducted, the forward recognition camera angle must be adjusted. For details, refer to the Repair Manual.
The forward recognition camera is removed and reinstalled or replaced.
Parts relating to the tires or suspension are replaced or adjusted.
A strong force is applied onto the forward recognition camera.
The LTA system does not operate if the vehicle approaches the lane marker (but does not cross it), as long as the vehicle remains parallel with the lane marker.
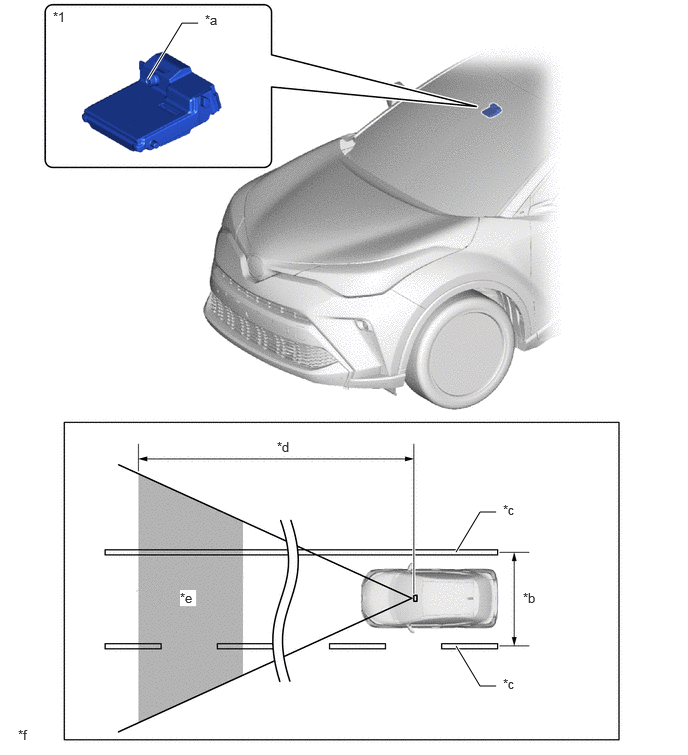
| *1 | Forward Recognition Camera | - | - |
| *a | Camera Sensor | *b | Approximately 3.0 m (9.8 ft.) or more |
| *c | Lane Marker | *d | Approximately 50 m (164 ft.) |
| *e | Camera Sensor Recognition Range | *f | The illustrations shown are examples only. |
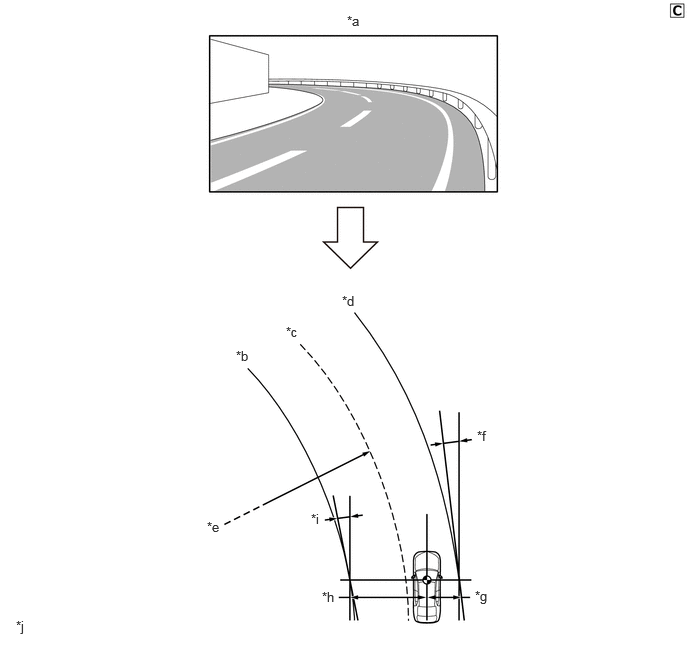
| *a | Image Captured by Forward Recognition Camera | *b | Left Lane Marker |
| *c | Center of Lane | *d | Right Lane Marker |
| *e | Lane Radius (If only the left lane marker or right lane marker is recognized, the radius of the recognized lane marker will be calculated.) | *f | Angle between Vehicle Traveling Direction and Right Lane Marker |
| *g | Distance from Center of Vehicle to Right Lane Marker | *h | Distance from Center of Vehicle to Left Lane Marker |
| *i | Angle between Vehicle Traveling Direction and Left Lane Marker | *j | The illustrations shown are examples only. |