LIGHTING (EXT) LIGHTING SYSTEM CONTROL AUTOMATIC HEADLIGHT BEAM LEVEL CONTROL
FUNCTION OF MAIN COMPONENTS
| Component | Function |
|---|---|
|
*1: Models with static control type automatic headlight beam level control system *2: Models with dynamic control type automatic headlight beam level control system |
|
| Headlight ECU Sub-assembly LH | ·
Controls the automatic headlight beam level control system. ·
Detects the vehicle posture and vehicle driving conditions based on the rear height control sensor sub-assembly LH and skid control ECU to control the headlight leveling motor LH*1 or headlight swivel motor LH*2. |
| Headlight ECU Sub-assembly RH | Controls the headlight leveling motor RH*1 or headlight swivel motor RH*2 according to control signals from the headlight ECU sub-assembly LH. |
| Headlight Leveling Motor LH/RH*1 | Moves the headlights vertically and controls the beam axis direction according to control signals from the headlight ECU sub-assembly LH/RH. |
| Headlight Swivel Motor LH/RH*2 | Moves the headlights vertically and controls the beam axis direction according to control signals from the headlight ECU sub-assembly LH/RH. |
| Brake Actuator Assembly
·
Skid Control ECU |
Transmits the vehicle speed signal to the headlight ECU sub-assembly LH. |
| Rear Height Control Sensor Sub-assembly LH | Detects vehicle movement and transmits a signal to the headlight ECU sub-assembly LH. |
| Headlight Dimmer Switch Assembly | Transmits a light control signal to the main body ECU (multiplex network body ECU). |
| Main Body ECU (Multiplex Network Body ECU) | Receives a light control signal and transmits it to the headlight ECU sub-assembly LH. |
SYSTEM CONTROL
Static Control Type
The headlight ECU sub-assembly LH receives vehicle height change signals sent from the rear height control sensor sub-assembly LH and calculates the changes in the pitch angle of the vehicle. The headlight ECU sub-assembly LH/RH drives the headlight leveling motor LH/RH in accordance with the change.
| Control Mode | Details |
|---|---|
| While Stopped | If the vehicle attitude is stable for approximately 3 seconds with the headlights on while stopped, the headlight ECU sub-assembly LH/RH operates the headlight leveling motor LH/RH in accordance with the detected change in vehicle attitude. |
Dynamic Control Type
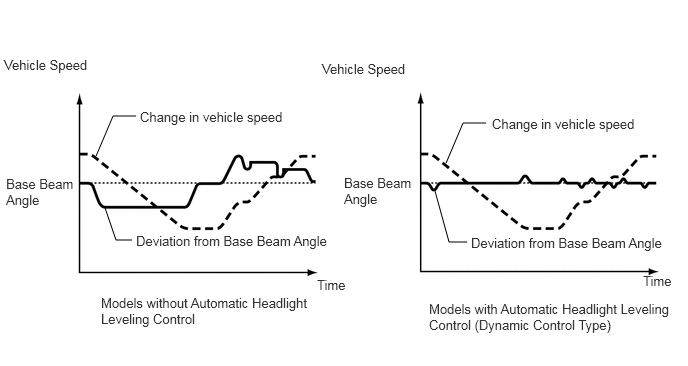
The headlight ECU sub-assembly LH receive changes in the height of the vehicle which is detected by the rear height control sensor LH and calculate the change in pitch of the vehicle.
The headlight ECU sub-assemblies adjust the vertical aim of the headlights based on the calculated angle of the vehicle in order to maintain a constant beam angle.
FUNCTION
Static Control Type
The rear height control sensor sub-assembly LH detects the changes in vehicles rear ride height due to cargo loads etc., and operates the headlight leveling motor RH/LH in accordance with the changes, keeping the headlight axes at a constant angle.
Dynamic Control Type
The headlight ECU sub-assemblies calculates changes in the vehicle posture based on the signals from the rear height control sensor sub-assembly LH.
Following this, the ECUs controls the headlight swivel motor based on this information, in order to change the projector headlight unit angle.
FAIL-SAFE
If the headlight ECU sub-assembly detects a malfunction in the automatic headlight beam level control system, the headlight ECU sub-assembly performs the fail-safe operation. For details, refer to the Repair Manual.