HYBRID / BATTERY CONTROL HYBRID CONTROL SYSTEM DETAILS MG1 AND MG2
CONSTRUCTION
Motor Generator No. 1 (MG1) and Motor Generator No. 2 (MG2)
MG1 and MG2, which are built into the hybrid vehicle transaxle assembly, are compact, lightweight, and highly efficient alternating current permanent magnet motors.
MG1 and MG2 respectively consist of a stator, stator coil, rotor, permanent magnets, and resolver.
MG1 charges the HV battery and supplies electrical power to drive MG2. In addition, MG1 regulates the generated electricity to change the MG1 speed, controlling the continuously variable transmission function of the transaxle effectively. MG1 also serves as a starter to start the engine.
MG2 drives the drive wheels using electrical power from MG1 or the HV battery. In addition, it acts as a generator when decelerating to charge the HV battery.
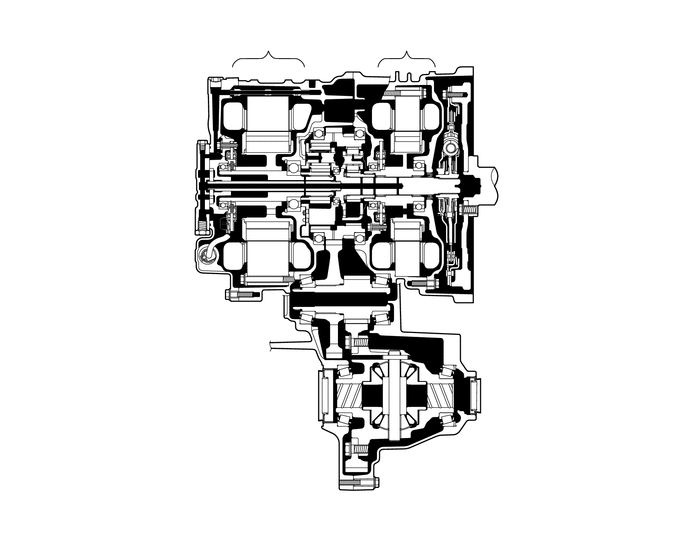
| *1 | MG2 | *2 | MG1 |
| *3 | Stator Coil | *4 | Permanent Magnet |
| *5 | Resolver | *6 | Rotor |
| *7 | Stator | - | - |
When a three-phase alternating current is passed through the three-phase windings of the stator coil, a rotating magnetic field is created in the electric motor. By controlling this rotating magnetic field according to the rotor rotational position and speed, the permanent magnets that are provided in the rotor become attracted by the rotating magnetic field, thus generating torque.
The generated torque is for all practical purposes proportional to the amount of current, and the rotational speed is controlled by the frequency of the alternating current. Furthermore, a high level of torque, all the way to high speeds, can be generated efficiently by properly controlling the relationship of the rotating magnetic field to the angle of the rotor magnets.
When the motor is used to generate electricity, the rotation of the rotor creates a rotating magnetic field, which creates current in the phases of the stator coils.
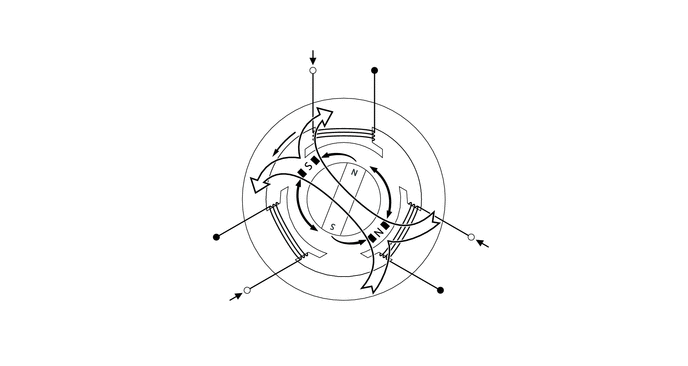
| *1 | Stator Coil (U Phase) | *2 | Stator Coil (V Phase) |
| *3 | Stator Coil (W Phase) | *4 | Rotor (Permanent Magnet) |
| *a | From Inverter with Converter Assembly | *b | Connected internally in the motor |
| *c | Rotating Magnetic Field | *d | Repulsion |
| *e | Attraction | - | - |
Resolver for MG1 and MG2
A resolver is an extremely reliable and compact sensor that precisely detects the magnetic pole position. Knowing the precise position of the magnetic poles of the rotor (MG1 and MG2) is indispensable for ensuring efficient control of MG1 and MG2. MG1 and MG2 each have their own resolver.
The stator of the resolver contains 3 types of coils: excitation coil A, detection coil S and detection coil C.
The rotor of the resolver is oval, the distance of the gap between the stator and the rotor varies with the rotation of the rotor.
The flow of an alternating current into the excitation coil A results in the creation of a constant frequency magnetic field. Using this constant frequency magnetic field, the coil S and coil C will output values that correspond to the position of the rotor. Therefore, the MG ECU detects the absolute position based on the difference between the coil S and coil C output values. Furthermore, the MG ECU calculates the rotational speed based on the amount of change in the position within a given length of time.
The +S and -S pairs of the detection coil S are staggered by 90 degrees. The +C and -C pairs of the detection coil C are also staggered in the same way. The S and C pairs of coils are located 45° from each other.
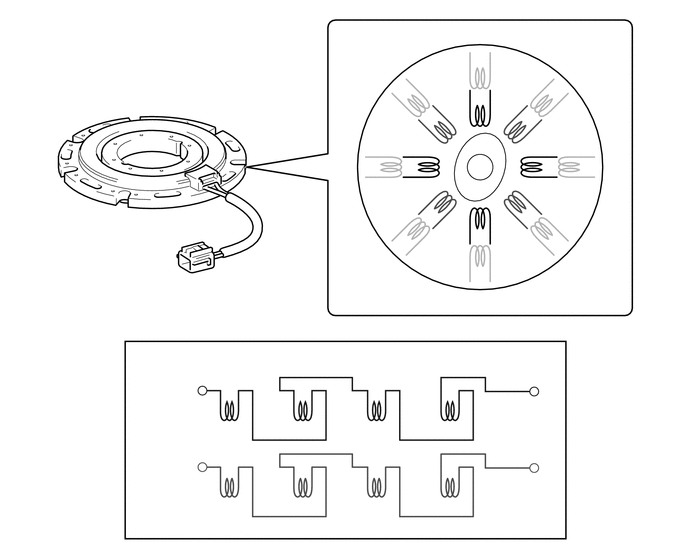
| *1 | +S (Detection Coil S) | *2 | +C (Detection Coil C) |
| *3 | -S (Detection Coil S) | *4 | -C (Detection Coil C) |
| *5 | Excitation Coil A | *6 | Rotor |
| *a | Image of Resolver Internal Construction | *b | Electrical Orientation of Resolver Coils |
| *c | Circuit of Detection Coil S | *d | Circuit of Detection Coil C |
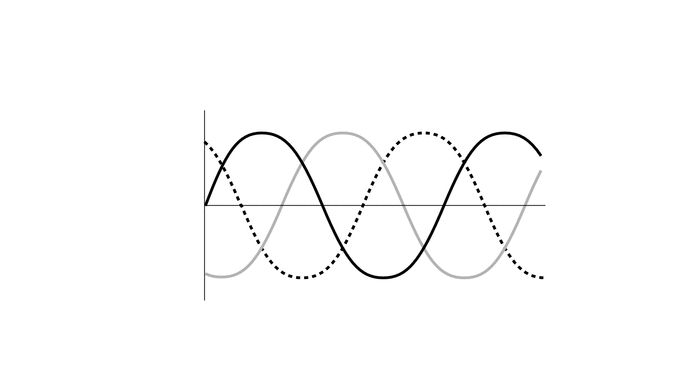
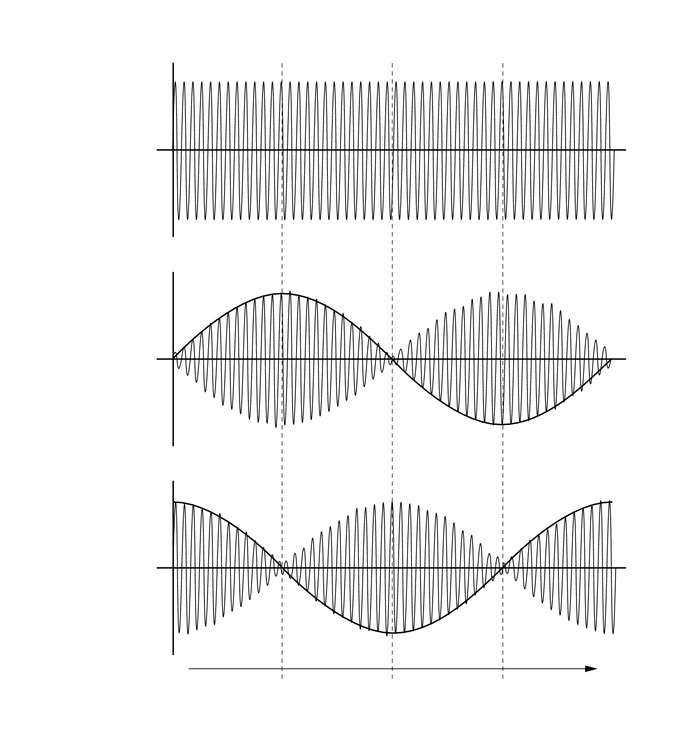
Because the excitation coil A is provided with an alternating current at a constant frequency, a constant frequency magnetic field is output to the coils S and C, regardless of the rotor speed. The magnetic field of the excitation coil A is carried to the coils S and C by the rotor. The rotor is oval, and the gap between the stator and the rotor varies with the rotation of the rotor. Due to the variation of the gap, the peak values of the waveforms output by the coils S and C vary in accordance with the position of the rotor.
The MG ECU constantly monitors these peak values, and connects them to form a virtual waveform. The MG ECU calculates the absolute position of the rotor from the difference between the values of the coils S and C. It determines the rotor direction based on the difference between the phases of the virtual waveform of the coil S and the virtual waveform of the coil C. Furthermore, the MG ECU calculates the rotational speed based on the amount of change in the rotor position within a given length of time.
The diagrams below illustrate the waveforms that are output at coils A, S and C when the rotor makes a positive rotation of 180° from a certain position.
Temperature Sensor for MG1 and MG2
The temperature sensors are used to detect the temperature of the MG1 and MG2 stators.
The power management control ECU optimally controls MG1 and MG2 according to the signals from each temperature sensor.