CRUISE CONTROL DYNAMIC RADAR CRUISE CONTROL SYSTEM DETAILS MILLIMETER WAVE RADAR SENSOR
CONSTRUCTION
The millimeter wave radar sensor assembly consists of a millimeter wave radar circuit, signal processing circuit, and CPU.
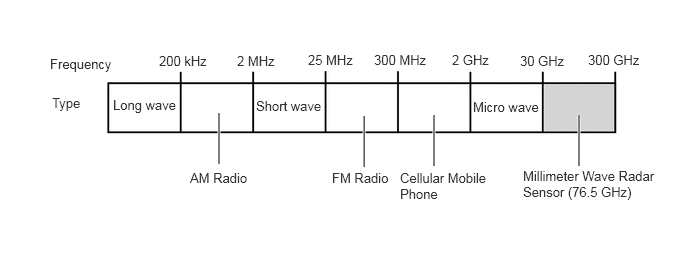
The millimeter wave radar outputs waves when the vehicle speed is 2 km/h (1.2 mph) or more, and does not when the vehicle speed is lower than 2 km/h (1.2 mph). The millimeter wave radar uses frequencies in the 76.5 GHz band.
The reception antennas receive the millimeter wave radar waves that have been reflected.
The signal processing circuit detects the distance, relative speed, and the direction of the object by generating millimeter wave radar waves and calculating the signals received by the reception antennas. Then, it transmits this information to the driving support ECU assembly.
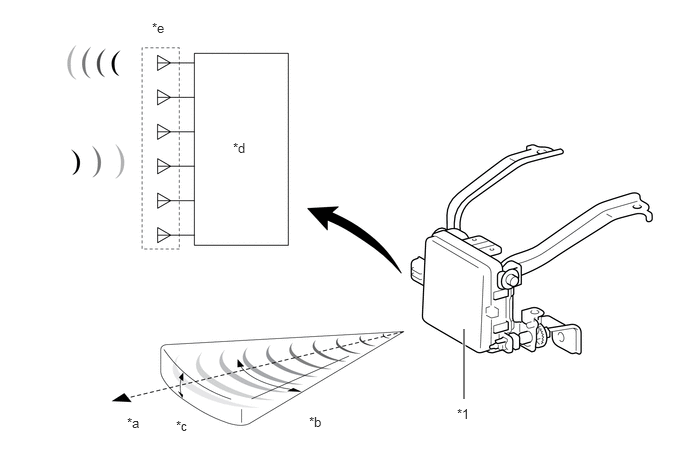
| *1 | Millimeter Wave Radar Sensor Assembly | - | - |
| *a | Detection Distance: Approximately 150 m (490 ft.) | *b | Horizontal Angle: About 20° |
| *c | Vertical Angle: About 4° | *d | Signal Processing Circuit |
| *e | Millimeter Wave Radar Circuit | - | - |
The distance to the object, azimuth, and relative speed are calculated from the information that is provided by the reflected millimeter wave radar waves as described below.
| Item | Calculation Method |
|---|---|
| Distance | Calculated from the length of time that has elapsed from the time the waves of the millimeter wave radar have been emitted, until the reflected waves are received by the millimeter wave radar circuit. The detection distance is approximately 150 m (490 ft.). |
| Azimuth | Calculated from the reception angle of the reflected millimeter wave radar waves. The detection angle has a horizontal range of approximately 20° and a vertical range of approximately 4°. |
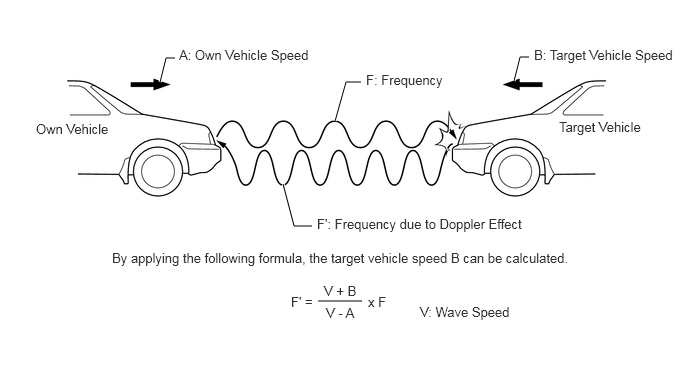
| Relative Speed | Calculated by utilizing the change (Doppler effect*) that occurs in the frequency of the reflected millimeter wave radar waves. |
- HINT:
-
*: The Doppler effect causes the observer to perceive the radio waves emitted by a moving object to be a higher frequency as it approaches, and to be a lower frequency as. it recedes. This phenomenon is created because when an object is located far away, the radio waves are perceived at higher frequency than those of the radio source.
- HINT:
- ·
Millimeter wave radar uses an extremely high frequency band between 30 GHz and 300 GHz, with an extremely short wavelength between 1 and 10 mm (0.04 to 0.40 in.) in a vacuum. The millimeter wave radar sensor of the pre-crash safety system uses frequencies in the 76.5 GHz band.
·Millimeter wave radar is less affected by weather conditions such as rain, fog, or snow, and provides excellent characteristics for recognizing objects. Therefore, it is well suited to the pre-crash safety system and the dynamic radar cruise control system.
·An SST is used if radar axis adjustment is needed. For details, refer to the Repair Manual.