PRE-COLLISION PRE-COLLISION SYSTEM CONTROL PRE-COLLISION CONTROL
FUNCTION OF MAIN COMPONENTS
| Item | Function | |
|---|---|---|
|
*1: For region A *2: Models with headup display |
||
| Millimeter Wave Radar Sensor Assembly | Radiates millimeter wave radar forward, uses the reflected millimeter waves for detecting the presence of a vehicle ahead, the vehicle-to-vehicle distance, and the relative speed, and then transmits this information to the forward recognition camera. | |
| Forward Recognition Camera | ·
Acquires information about a preceding vehicle, pedestrian or bicyclists. ·
Determines whether a collision is imminent based on the information received from each sensor. Sends control signals to the skid control ECU when it determines that there is a possibility of a collision or a collisions is imminent based on the information received from each sensor. ·
Controls the supply of electric current to the camera heater when the ambient temperature is low. ·
Outputs an emergency steering assist request signal to the power steering ECU assembly when the system judges that it is necessary to assist the driver in performing evasive action. |
|
| Forward Recognition with Heater Hood Sub-assembly | Camera Heater | Control is performed by the forward recognition camera to supply electric current and heat the heater, preventing the windshield glass in front of the forward recognition camera from fogging up. |
| Brake Actuator Assembly | Skid Control ECU | ·
Receives a brake assist standby request signal from the millimeter wave radar sensor assembly and switches the brake assist to standby mode. When a master cylinder pressure signal is input, it activates the brake assist. ·
Receives a pre-collision braking request signal from the millimeter wave radar sensor assembly, and then applies the brakes. ·
Transmits vehicle speed signals to the forward recognition camera. |
| Rack & Pinion Power Steering Gear Assembly*1 | Power Steering ECU | Controls the power steering motor according to signals from the forward recognition camera. |
| Speed Sensors | Detect the wheel speed of each of the 4 wheels and transmits the signal to the skid control ECU. | |
| Airbag Sensor Assembly | Yawrate Sensor | Detects the yaw rate and lateral/longitudinal deceleration of the vehicle and transmits the signal to the forward recognition camera. |
| Steering Sensor | Detects the angle and direction of steering and transmits a signal to the forward recognition camera. | |
| Stop Light Switch Assembly | ·
Receives a stop light turn on request signal from the skid control ECU, and turns on the stop lights. ·
Detects if the brake pedal is depressed and transmits a signal to the skid control ECU. |
|
| VSC OFF Switch | Disables the pre-collision braking and pre-collision brake assist operation when VSC OFF mode. | |
| Combination Meter Assembly | PCS Warning Light | ·
Illuminates to warn the driver in accordance with signals from the forward recognition camera. ·
Illuminates when the system is malfunctioning or temporarily disabled. ·
Illuminates when the pre-collision system is not available. ·
Illuminates when pre-collision braking and pre-collision brake assist operation are disabled using the VSC OFF switch. |
| Multi-information Display | ·
Displays a warning message to inform or warn the driver of the system condition in accordance with signals from the forward recognition camera. ·
Disables the pre-collision system operation when selected PCS OFF mode in setting display function. ·
Changing the pre-collision warning timing when selected Early/Middle/Late in setting display function. |
|
| VSC OFF Indicator Light | Illuminates when the VSC is not available. | |
| LTA Indicator | Illuminates when emergency steering assist operates. | |
| Master Warning Light | Illuminates to warn the driver in accordance with signals from the forward recognition camera. | |
| Buzzer | Sounds to warn the driver in accordance with signals from the forward recognition camera. | |
| Meter Mirror Sub-assembly*2 | Shows a warning message to warn the driver on the headup display. | |
| ECM | ·
Detects the accelerator pedal opening angle and sends that information to the forward recognition camera. ·
Performs engine output control based on information from the forward recognition camera. |
|
| Steering Pad Switch Assembly | Switch the display of multi-information display within combination meter assembly. | |
| Main Body ECU (Multiplex Network Body ECU) | Outputs the specification signal of the vehicle to forward recognition camera. | |
| Network Gateway ECU | Transmits the signal between the CAN communication bus. | |
| Ambient Temperature Sensor (Thermistor Assembly) | Detects the ambient temperature and transmits signals to the air conditioning amplifier assembly. | |
| Air Conditioning Amplifier Assembly | Transmits ambient temperature signals to the forward recognition camera. | |
FUNCTION
Pre-collision warning
When the system determines that the possibility of a frontal collision is high, a buzzer will sound and a warning message will be displayed on the multi-information display to urge the driver to take evasive action.
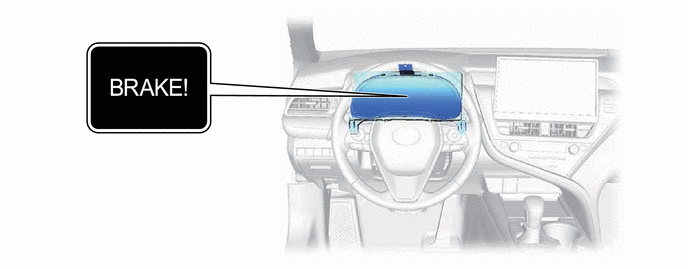
The illustrations shown are examples only.
Pre-collision brake assist
When the system determines that the possibility of a frontal collision is high, the system applies greater braking force in relation to how strongly the brake pedal is depressed.
Pre-collision braking
If the system determines that the possibility of a frontal collision is extremely high, the brakes are automatically applied to help avoid the collision or reduce the impact of the collision.
Emergency steering assist (for region A)
If the system determines that the possibility of a frontal collision is high and that there is sufficient space for the vehicle to be steered into within its lane, and the driver has begun evasive maneuver or steering, emergency steering assist will assist the steering movements to help enhance the vehicle stability and for lane departure prevention. During operation, the indicator will illuminate in green.
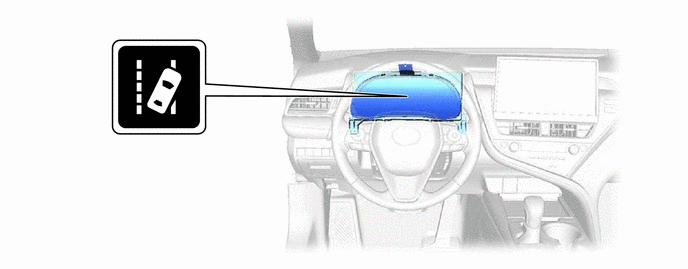
The illustrations shown are examples only.
Intersection right/left turn assistance (for region A)
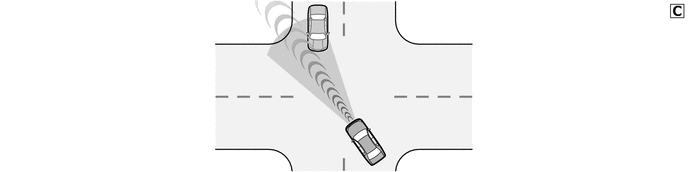
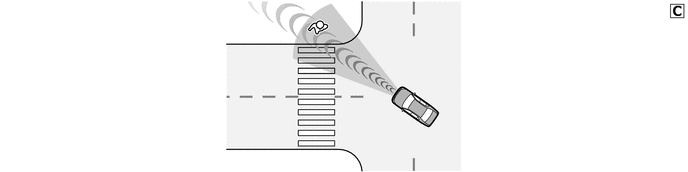
If the system determines that there is a high possibility of a collision in the following situations, it will assist with pre-collision warning and, if necessary pre-collision braking. Depending on the configuration of the intersection, it may not be possible to support.
When you turn right/left at an intersection and cross the path of an oncoming vehicle.
When you turn right/left, pedestrian is detected in the forward direction and estimated to enter your vehicle's path. (bicyclists are not detected.)
OPERATING CONDITION
Operational conditions for each pre-collision function
The pre-collision system is enabled and the system determines that the possibility of a frontal collision with a detected object is high. The system may not operate in the following situations:
If a battery terminal has been disconnected and reconnected and then the vehicle has not been driven for a certain amount of time.
If the shift lever is in R.
When the VSC OFF indicator is illuminated (only the pre-collision warning function will be operational).
The operation speeds and operation cancellation for each function is listed below.
| Detectable objects | Vehicle speed | Relative speed between your vehicle and object |
|---|---|---|
| Preceding and stopped vehicles | Approximately 10 to 180 km/h (7 to 110 mph) | Approximately 10 to 180 km/h (7 to 110 mph) |
| For region A and B: Oncoming vehicles | Approximately 10 to 180 km/h (7 to 110 mph) | Approximately 20 to 180 km/h (13 to 110 mph) |
| For region A and B: Bicyclists and pedestrians | Approximately 10 to 80 km/h (7 to 50 mph) | Approximately 10 to 80 km/h (7 to 50 mph) |
While the pre-collision warning function is operating, if the steering wheel is operated heavily or suddenly, the pre-collision warning may be cancelled.
| Detectable objects | Vehicle speed | Relative speed between your vehicle and object |
|---|---|---|
| Preceding and stopped vehicles | Approximately 30 to 180 km/h (20 to 110 mph) | Approximately 30 to 180 km/h (20 to 110 mph) |
| For region A and B: Bicyclists and pedestrians | Approximately 30 to 80 km/h (20 to 50 mph) | Approximately 30 to 80 km/h (20 to 50 mph) |
| Detectable objects | Vehicle speed | Relative speed between your vehicle and object |
|---|---|---|
| Preceding and stopped vehicles | Approximately 10 to 180 km/h (7 to 110 mph) | Approximately 10 to 180 km/h (7 to 110 mph) |
| For region A and B: Oncoming vehicles | Approximately 10 to 180 km/h (7 to 110 mph) | Approximately 20 to 180 km/h (13 to 110 mph) |
| For region A and B: Bicyclists and pedestrians | Approximately 10 to 80 km/h (7 to 50 mph) | Approximately 10 to 80 km/h (7 to 50 mph) |
If either of the following occur while the pre-collision braking function is operating, it will be canceled:
The accelerator pedal is depressed strongly.
The steering wheel is turned sharply or abruptly.
When the turn signal lights are flashing, emergency steering assist will not operate in case of an emergency.
| Detectable objects | Vehicle speed | Relative speed between your vehicle and object |
|---|---|---|
| Preceding and stopped vehicles, bicyclists and pedestrians | Approximately 40 to 80 km/h (25 to 50 mph) | Approximately 40 to 80 km/h (25 to 50 mph) |
If any of the following occur while the emergency steering assist function is operating, it will be canceled:
The accelerator pedal is depressed strongly.
The steering wheel is turned sharply or abruptly.
The brake pedal is depressed.
When the turn signal lights are not flashing, support for turning left or right at an intersection which targets oncoming vehicles does not work.
| Detectable objects | Vehicle speed | Oncoming vehicle speed | Relative speed between your vehicle and object |
|---|---|---|---|
| Oncoming vehicles | Approximately 10 to 25 km/h (7 to 15 mph) | Approximately 30 to 55 km/h (20 to 35 mph) | Approximately 40 to 80 km/h (25 to 50 mph) |
| Pedestrians | Approximately 10 to 25 km/h (7 to 15 mph) | - | Approximately 10 to 25 km/h (7 to 15 mph) |
When the turn signal lights are not flashing, support for turning left or right at an intersection which targets oncoming vehicles does not work.
| Detectable objects | Vehicle speed | Oncoming vehicle speed | Relative speed between your vehicle and object |
|---|---|---|---|
| Oncoming vehicles | Approximately 15 to 25 km/h (10 to 15 mph) | Approximately 30 to 45 km/h (20 to 28 mph) | Approximately 45 to 70 km/h (28 to 43 mph) |
| Pedestrians | Approximately 10 to 25 km/h (7 to 15 mph) | - | Approximately 10 to 25 km/h (7 to 15 mph) |
Object detection function
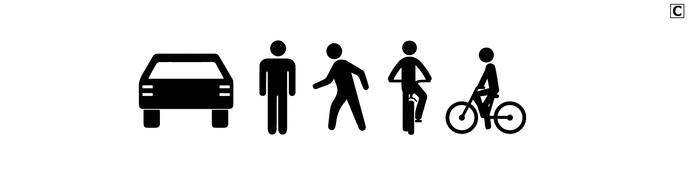
The system detects objects based on their size, profile, motion, etc. However, an object may not be detected depending on the surrounding brightness and the motion, posture, and angle of the detected object, preventing the system from operating properly. The illustration shows an image of detectable objects.
Conditions under which the system may operate even if there is no possibility of a collision.
In some situations such as the following, the system may determine that there is a possibility of a frontal collision and operate.
When passing a detectable object, etc.
When changing lanes while overtaking a detectable object, etc.
When approaching a detectable object in an adjacent lane or on the roadside, such as when changing the course of travel or driving on a winding road.
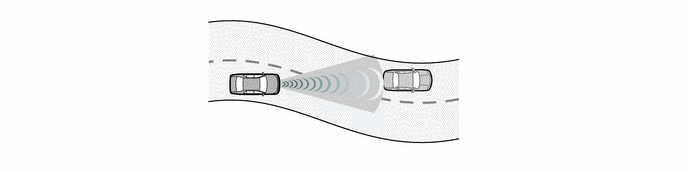
When rapidly closing on a detectable object, etc.
When approaching objects on the roadside, such as detectable objects, guardrails, utility poles, trees, or walls.
When there is a detectable object or other object by the roadside at the entrance of a curve.
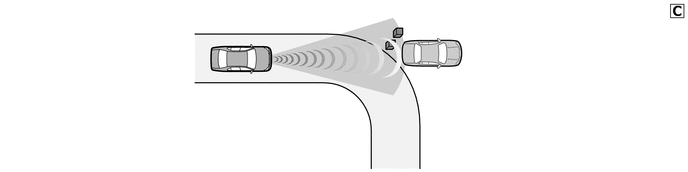
When there are patterns or paint in front of your vehicle that may be mistaken for a detectable object.
When the front of your vehicle is hit by water, snow, dust, etc.
When overtaking a detectable object that is changing lanes or making a right/left turn.
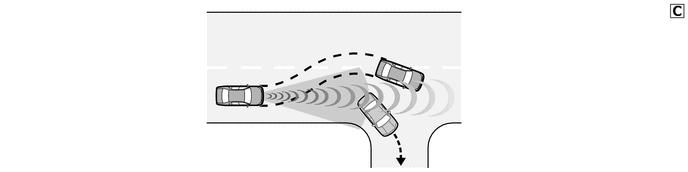
When passing a detectable object in an oncoming lane that is stopped to make a right/left turn.
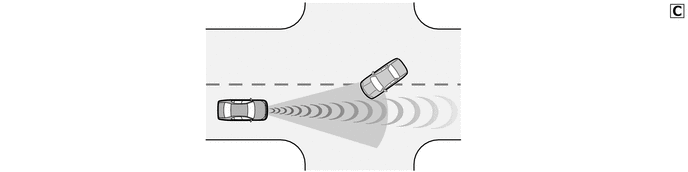
When a detectable object approaches very close and then stops before entering the path of your vehicle.
If the front of your vehicle is raised or lowered, such as when on an uneven or undulating road surface.
When driving on a road surrounded by a structure, such as in a tunnel or on an iron bridge.
When there is a metal object (manhole cover, steel plate, etc.), steps, or a protrusion in front of your vehicle.
When passing under an object (road sign, billboard, etc.).
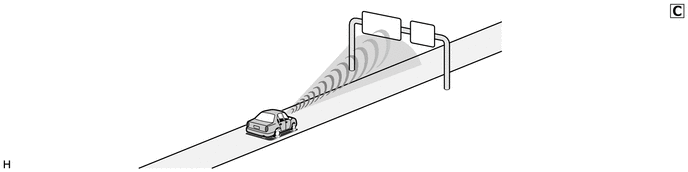
When approaching an electric toll gate barrier, parking area barrier, or other barrier that opens and closes.
When using an automatic car wash.
When driving through or under objects that may contact your vehicle, such as thick grass, tree branches, or a banner.
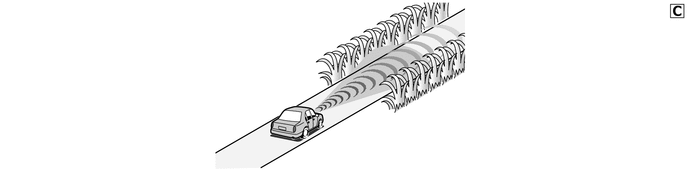
When driving through steam or smoke.
When driving near an object that reflects radio waves, such as a large truck or guardrail.
When driving near a TV tower, broadcasting station, electric power plant, radar equipped vehicles, etc., or other location where strong radio waves or electrical noise may be present.
When there are many things which can reflect the radio waves of the radar in the vicinity (tunnels, truss bridges, gravel roads, snow covered road that have tracks, etc.).
For region A: While making a right/left turn, when an oncoming vehicle or a crossing pedestrian has already exited the path of your vehicle.
For region A: While making a right/left turn, closely in front of an oncoming vehicle or a crossing pedestrian.
For region A: While making a right/left turn, when an oncoming vehicle or a crossing pedestrian stops before entering the path of your vehicle.
For region A: While making a right/left turn, when an oncoming vehicle turns right/left in front of your vehicle.
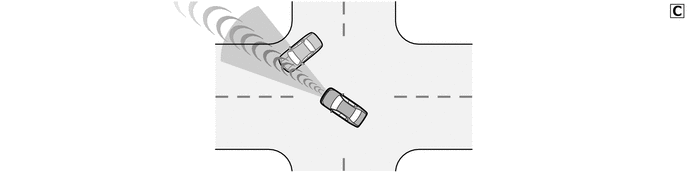
For region A: While steering into the direction of oncoming traffic.
Situations in which the system may not operate properly
In some situations such as the following, an object may not be detected by the millimeter wave radar sensor assembly and forward recognition camera, preventing the system from operating properly:
When a detectable object is approaching your vehicle.
When your vehicle or a detectable object is wobbling.
If a detectable object makes an abrupt maneuver (such as sudden swerving, acceleration or deceleration).
When your vehicle approaches a detectable object rapidly.
When a detectable object is not directly in front of your vehicle.
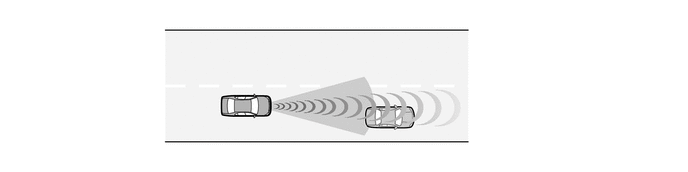
When a detectable object is near a wall, fence, guardrail, manhole cover, vehicle, steel plate on the road, etc.
When a detectable object is under a structure.
When part of a detectable object is hidden by an object, such as large baggage, an umbrella, or guardrail.
When there are many things which can reflect the radio waves of the radar in the vicinity (tunnels, truss bridges, gravel roads, snow covered road that have tracks, etc.).
When there is an effect on the radio waves to the radar that is installed on another vehicle.
When multiple detectable objects are close together.
If the sun or other light is shining directly on a detectable object.
When a detectable object is a shade of white and looks extremely bright.
When a detectable object appears to be nearly the same color or brightness as its surroundings.
If a detectable object cuts or suddenly emerges in front of your vehicle.
When the front of your vehicle is hit by water, snow, dust, etc.
When a very bright light ahead, such as the sun or the headlights of oncoming traffic, shines directly into the forward recognition camera.
When approaching the side or front of a vehicle ahead.
For region C: If a vehicle ahead is a motorcycle or bicycle
If a vehicle ahead is narrow, such as a personal mobility vehicle.
If a preceding vehicle has a small rear end, such as an unloaded truck.
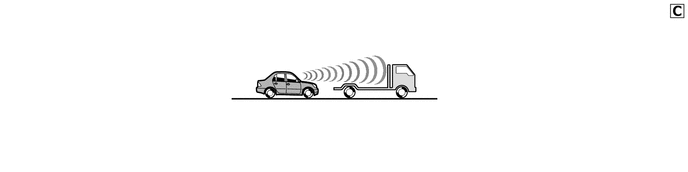
If a preceding vehicle has a low rear end, such as a low bed trailer.
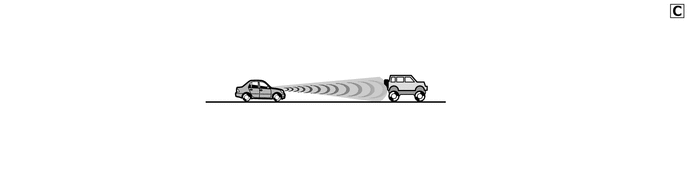
If a vehicle ahead has extremely high ground clearance.
If a vehicle ahead is carrying a load which protrudes past its rear bumper.
If a vehicle ahead is irregularly shaped, such as a tractor or side car.
For region A and B: If a vehicle ahead is a child sized bicycle, a bicycle that is carrying a large load, a bicycle ridden by more than one person, or a uniquely shaped bicycle (bicycle with a child seat, tandem bicycle, etc.).
For region A and B: If a pedestrian/or the riding height of a bicyclist ahead is shorter than approximately 1 m (3.2 ft.) or taller than approximately 2 m (6.5 ft.).
For region A and B: If a pedestrian/bicyclist is wearing oversized clothing (a rain coat, long skirt, etc.), making their silhouette obscure.
For region A and B: If a pedestrian is bending forward or squatting or bicyclist is bending forward.
For region A and B: If a pedestrian/bicyclist is moving fast.
For region A and B: If a pedestrian is pushing a stroller, wheelchair, bicycle or other vehicle.
When driving in inclement weather such as heavy rain, fog, snow or a sandstorm.
When driving through steam or smoke.
When the surrounding area is dim, such as at dawn or dusk, or while at night or in a tunnel, making a detectable object appear to be nearly the same color as its surroundings.
When driving in a place where the surrounding brightness changes suddenly, such as at the entrance or exit of a tunnel.
After the engine has started the vehicle has not been driven for a certain amount of time.
While making a left/right turn and for a few seconds after making a left/right turn.
While driving on a curve and for a few seconds after driving on a curve.
If your vehicle is skidding.
If the front of the vehicle is raised or lowered.
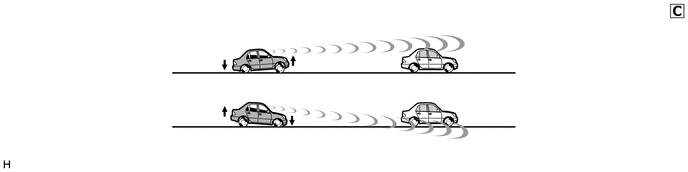
If the wheels are misaligned.
If a wiper blade is blocking the forward recognition camera.
The vehicle is being driven at extremely high speeds.
When driving on a hill.
If the millimeter wave radar sensor assembly or forward recognition camera is misaligned.
For region A: When driving in a traffic lane separated by more than one lane where oncoming vehicles are driving while making a right/left turn.
For region A: When largely out of place with the opposite facing targeted oncoming vehicle during a right/left turn.
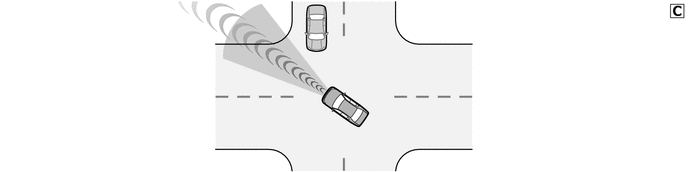
For region A: While making a right/left turn, when a pedestrian approaches from behind or side of your vehicle.
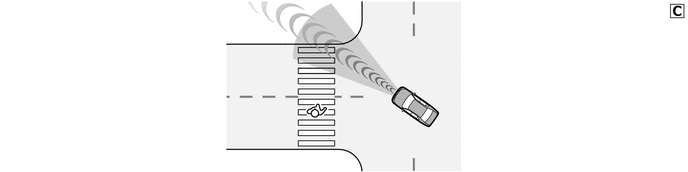
In addition to the above, in some situations, such as the following, the emergency steering assist may not operate (for region A):
When the white (yellow) lane lines are difficult to see, such as when they are faint, diverging/merging, or a shadow is cast upon them.
When the lane is wider or narrower than normal.
When there is a light and dark pattern on the road surface, such as due to road repairs.
When the target is too close.
When there is insufficient safe or unobstructed space for the vehicle to be steered into.
If oncoming vehicle is present.
If VSC function is operating.
In some situations such as the following, sufficient braking force (for region A) or steering force may not be obtained, preventing the system from performing properly:
If the braking functions cannot operate to their full extent, such as when the brake parts are extremely cold, extremely hot, or wet.
If the vehicle is not properly maintained (brakes or tires are excessively worn, improper tire inflation pressure, etc.).
When the vehicle is being driven on a gravel road or other slippery surface.
When the road surface has deep wheel tracks.
When driving on a hill road.
When driving on a road that has inclines to the left or right.
If VSC is disabled:
If VSC is disabled, the pre-collision brake assist and pre-collision braking functions are also disabled.
The PCS warning light will turn on and "VSC Turned Off Pre-Collision Brake System Unavailable" will be displayed on the multi-information display.
If a warning light illuminates:
When a buzzer sounds simultaneously:
Indicates a malfunction has occurred in the PCS (Pre-Collision System).
If a buzzer does not sound:
The PCS (Pre-Collision System) has become temporarily unavailable, corrective action may be necessary.
Follow the instructions displayed on the multi-information display.
Click here
Click hereVehicle Interior>PRE-COLLISION>PRE-COLLISION SYSTEM>INDICATOR LIGHT/WARNING LIGHT/MULTI DISPLAY
- HINT:
-
If the PCS (Pre-Collision System) or VSC (Vehicle Stability Control) system is disabled, the PCS warning light will illuminate.
If a warning message is displayed:
If a message that indicates the malfunction of the forward recognition camera is displayed. The following systems may be suspended until the problem shown in the message is resolved.
Click hereVehicle Interior>PRE-COLLISION>PRE-COLLISION SYSTEM>INDICATOR LIGHT/WARNING LIGHT/MULTI DISPLAY
PCS (Pre-Collision System)
LTA (Lane Tracing Assist)
AHB (Automatic High Beam)
Dynamic radar cruise control
Dynamic radar cruise control with full-speed range*
*: Models with full-speed range following function
If a message that indicates the malfunction of the millimeter wave radar sensor assembly is displayed. The following systems may be suspended until the problem shown in the message is resolved.
Click hereVehicle Interior>PRE-COLLISION>PRE-COLLISION SYSTEM>INDICATOR LIGHT/WARNING LIGHT/MULTI DISPLAY
PCS (Pre-Collision System)
LTA (Lane Tracing Assist)
Dynamic radar cruise control
Dynamic radar cruise control with full-speed range*
*: Models with full-speed range following function
SYSTEM CONTROL
Pre-collision Brake Assist
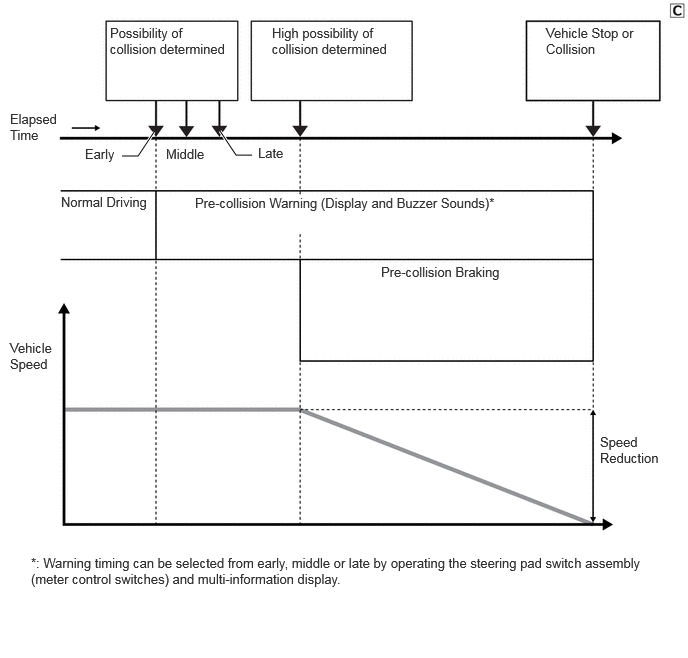
When the driver depresses the brake pedal after the pre-collision system has determined that there is the possibility of a collision, brake fluid pressure is increased. If the possibility of a collision is still high, brake fluid pressure is further increased.
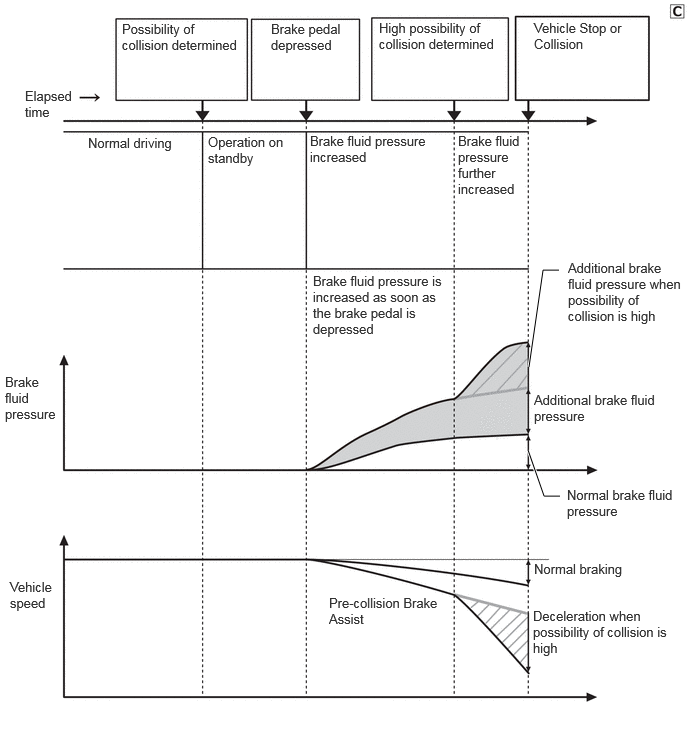
Pre-collision Braking
When the pre-collision system determines that a collision is imminent, the system performs pre-collision braking control.
Emergency Steering Assist (for region A)
Pre-collision Warning
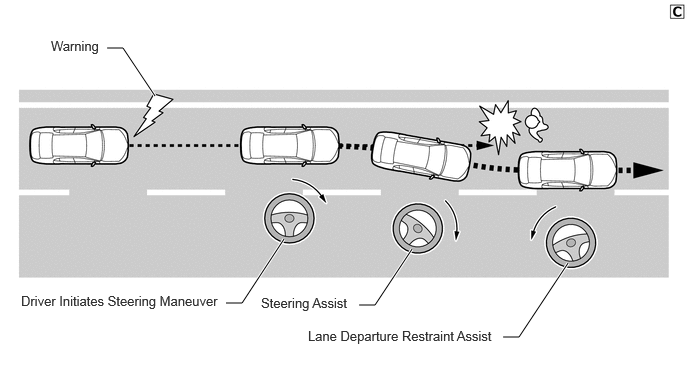
When the system determines that the possibility of a frontal collision is high, a buzzer will sound and a warning message will be displayed on the multi-information display.
Steering Assist
When the system determines that the possibility of a frontal collision is high, and based on recognition of white (yellow) lane lines and obstacle recognition, if the system is able to compute an evasive steering route within this vehicle's own lane of travel, then when the driver initiates steering operations to avoid the collision, the system performs steering assist to help enhance the vehicle stability.
Lane Departure Restraint Assist
The system performs lane departure restraint assistance to help keep the vehicle within its own lane of travel.
DIAGNOSIS
Initial Check
The forward recognition camera performs an initial check on the system for approximately 3 seconds after the ignition switch has been turned on (IG).
Monitor Function
After completing the initial check, the pre-collision system becomes ready to operate. During this time, the forward recognition camera periodically monitors the system for any malfunctions.
Diagnostic Trouble Code (DTC)
If the forward recognition camera detects a malfunction in the pre-collision system, it stores a 7 digit Diagnostic Trouble Code (DTC) in memory.