CRUISE CONTROL LANE DEPARTURE ALERT SYSTEM (w/ Yaw Assist Function) GENERAL GENERAL
OUTLINE
The lane departure alert system uses a forward recognition camera to detect lane markers on the road surface, assists the driver's steering operation by using the warning buzzer or steering vibration and brake control, and activates the lane departure warning when needed.
The lane departure alert system also operates on roads with any one lane marker.
The lane departure alert system is controlled by the forward recognition camera.
The following functions in the lane departure alert system operate according to switch operation and driving conditions.
|
*: Boundary between asphalt area and grass, dirt, curbs, etc. |
||
| Package Name | Toyota Safety Sense | |
| System Name | Lane Departure Alert | |
| Abbreviation | LDA | |
| Lane Departure Alert Function | Lane Marker | ○ |
| Lane Boundary* | ○ | |
| Yaw Assist Function | Lane Marker | ○ |
| Lane Boundary* | ○ | |
| Vehicle Sway Warning Function | ○ | |
- HINT:
-
○: Available
-
-: Not available
PRECAUTION
Lane Departure Alert System Handling Precautions
The lane departure alert system provides information to the driver and performs yaw assistance according to road and driving conditions. The driver cannot take his or her hands off from the steering wheel while the system is operating, so the driver must not trust solely in the system, and must always remain aware of surrounding conditions and the direction the vehicle is headed, operate the steering wheel to adjust the vehicle's path and ultimately be responsible for driving in any case.
The lane departure alert system uses a forward recognition camera to recognize lane markers or lane boundaries, and operates by using the forward recognition camera, millimeter wave radar sensor assembly to recognize preceding and surrounding vehicles. The lane departure alert system does not operate if it cannot recognize lane markers or lane boundaries. Also, since an unnecessary yaw assist could be applied, or warning sounds may be produced when lane markers, make sure to drive appropriately using the steering wheel even when using the system. However, the yaw assist generated is small and does not interfere with operation of the vehicle.
The lane departure alert function and yaw assist function operate when the LDA main switch is on, and lane markers or lane boundaries are recognized when driving at or above the system operation vehicle speed. However, the systems may not operate (or may stop operating) depending on road or driving conditions.
If the system detects some kind of malfunction, it notifies the driver by buzzer and display, and then the system stops. However, the vehicle can be driven normally. If the system reports a malfunction after restarting the engine, have the vehicle inspected.
If not using the lane departure alert system in order to prevent incorrect operation, turn the system off with the LDA main switch.
Do not use the lane departure alert system under the following conditions.
Vehicle is driven on a road surface which is slippery due to rainy weather, fallen snow, freezing, etc.
Vehicle is driven on a snow covered road.
White (yellow) lines are difficult to see due to rain, snow, fog, dust, etc.
Vehicle is driven in a temporary lane or restricted lane due to construction work.
Vehicle is driven in a construction zone.
A spare tire, tire chains, etc. are equipped.
When the tires have been excessively worn, or when the tire inflation pressure is low.
When tires of a size other than specified are installed.
Vehicle is driven in traffic lanes other than that highways and freeways.
During emergency towing.
When the vehicle is towing a trailer.
Precautions to prevent failure or incorrect operation of the lane departure alert system.
Do not modify the headlights or place stickers, etc. on the surface of the lights.
Do not modify the suspension etc. If the suspension etc. needs to be replaced, contact your Toyota dealer.
Do not install or place anything on the hood or grille. Also, do not install a grille guard (bull bars, kangaroo bar, etc.).
If your windshield needs repairs, contact your Toyota dealer.
Do not use the lane departure alert system under the following conditions. Doing so could cause the system to operate improperly or could even lead to an unforeseen accident.
When driving around a sharp curve.
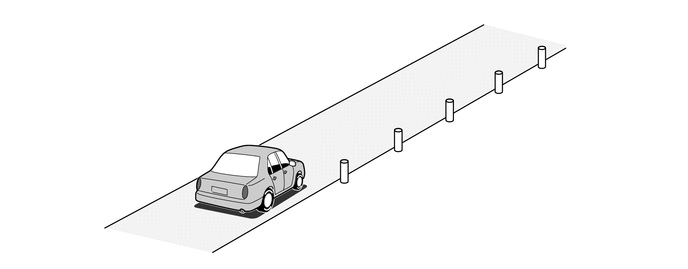
When driving on a road where structures or patterns on the side of the road could be mistaken as lane markers (such as guard rails, curbs or reflective poles).
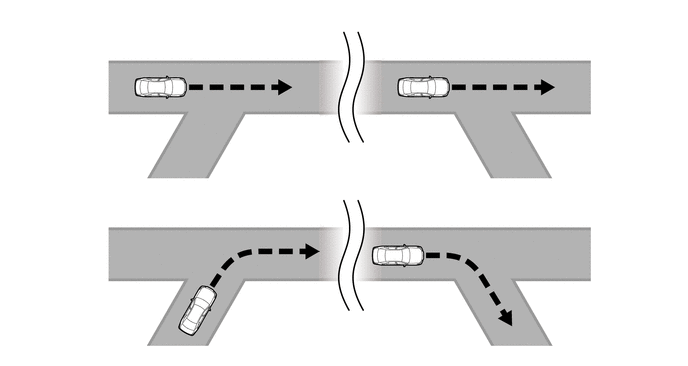
When driving through a junction or merging.
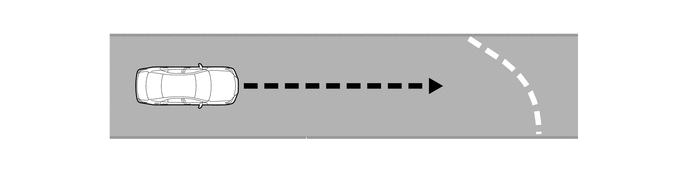
When driving on a repaired road on which there are traces of asphalt repair or old lane markers.
There are shadows on the road that run parallel with, or cover, the white (yellow) lines.
The vehicle is driven in an area without white (yellow) lines, such as in front of a tollgate or checkpoint, or at an intersection, etc.
The white (yellow) lines are cracked, "Botts' dots", "Raised pavement marker" or stones are present.
The white (yellow) lines cannot be seen or are difficult to see due to sand, etc.
The vehicle is driven on a road surface that is wet due to rain, puddles, etc.
The traffic lines are yellow (which may be more difficult to recognize than lines that are white).
The white (yellow) lines cross over a curb, etc.
The vehicle is driven on a bright surface, such as concrete.
If the edge of the road is not clear or straight.
The vehicle is driven on a surface that is bright due to reflected light, etc.
The vehicle is driven in an area where the brightness changes suddenly, such as at the entrances and exits of tunnels, etc.
Light from the headlights of an oncoming vehicle, the sun, etc. enters the camera.
The vehicle is driven on a slope.
The vehicle is driven on a road which tilts left or right, or a winding road.
The vehicle is driven on an unpaved or rough road.
The traffic lane is excessively narrow or wide.
The vehicle is extremely tilted due to carrying heavy luggage or having improper tire pressure.
The distance to the preceding vehicle is extremely short.
The vehicle is moving up and down a large amount due to road conditions during driving (poor roads or road seams).
When driving in a tunnel or at night with the headlights off or when a headlight is dim due to its lens being dirty or it being misaligned.
The vehicle is struck by a crosswind.
The vehicle has just changed lanes or crossed an intersection.
Tires which differ by structure, manufacturer, brand or tread pattern are used.
Snow tires, etc. are equipped.
The vehicle is being driven at extremely high speeds.
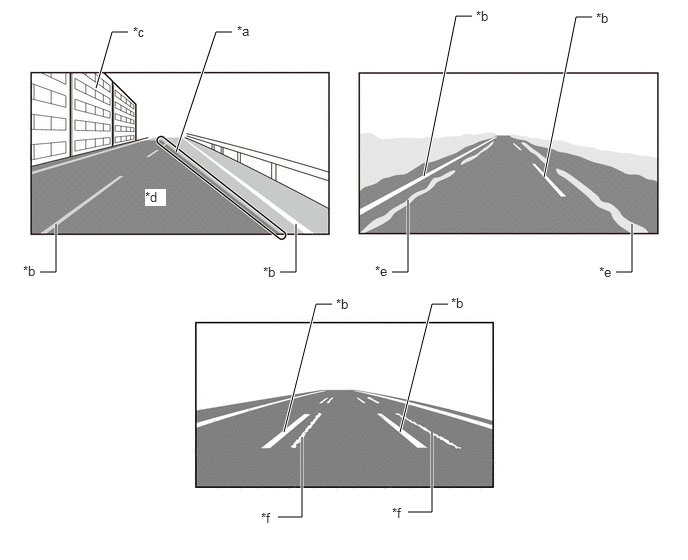
| *a | Edge of Shadow that could be Incorrectly Recognized as Lane Marker | *b | Lane Marker that should be Detected |
| *c | Structure | *d | Shadow of Structure |
| *e | Snow that could be Incorrectly Recognized as Lane Marker | *f | Trace of Erased Lane Marker that could be Incorrectly Recognized as Lane Marker |
See the PRE-COLLISION SYSTEM section for details on the handling precautions of the millimeter wave radar sensor assembly and forward recognition camera.