LIGHTING (EXT) LIGHTING SYSTEM CONTROL AUTOMATIC HIGH BEAM
FUNCTION OF MAIN COMPONENTS
| Component | Function |
|---|---|
|
*1: Models with high grade headlight *2: Models with standard grade headlight *3: Gasoline models *4: HV models |
|
| Forward Recognition Camera | Determines when to turn the high beams on and off after identifying the lights of oncoming vehicles, preceding vehicles and other lights from the picture information of its camera sensor. Then, the sensor sends high beam request signals to the main body ECU (multiplex network body ECU). |
| Main Body ECU (Multiplex Network Body ECU) | ·
Receives a switch on signal from the automatic high beam switch (auto high beam switch)). ·
Receives an AUTO or head position signal and high beam position signal from the turn signal switch. ·
Receives the high beam request signal from the forward recognition camera and sends a signal to DIM relay.*1 ·
Receives the high beam request signal from the forward recognition camera and sends a signal to headlights.*2 |
| No. 1 Engine Room Relay Block and No. 1 Junction Block Assembly
·
H-LP LH Relay ·
H-LP RH Relay ·
DIM Relay*1 |
·
Supplies power to the headlights. ·
Receives the high beam request signal from the DIM relay and sends a signal to headlights.*1 |
| ECM*3 | Sends a signal to indicate that the shift lever is in R. Based on this signal, the forward recognition camera determines the direction of vehicle movement. |
| Hybrid Vehicle Control ECU*4 | |
| Brake Actuator Assembly
·
Skid Control ECU*3 ·
No. 2 Skid Control ECU*4 |
Sends information about the average speed of the driving wheels. This information is used by the forward recognition camera to control switching between the high and low beams of the automatic high beam system. |
| Combination Meter Assembly | ·
Illuminates the automatic high beam indicator to inform the driver when the automatic high beam system is activated. ·
Illuminates the high beam indicator light to inform the driver when the high beams are on. ·
Displays a warning message when a malfunction is detected in the automatic high beam system. |
| Airbag Sensor Assembly*3 | Sends yawrate information to the forward recognition camera. |
| Yawrate Sensor*4 | |
| Automatic Light Control Sensor | Detects the ambient light level and sends a signal to the main body ECU (multiplex network body ECU). |
| Automatic High Beam Switch (Auto High Beam Switch) | Sends the switch on signal to the main body ECU (multiplex network body ECU). |
| Turn Signal Switch
·
Light Control Switch ·
Headlight Dimmer Switch |
Sends the light control switch signal and headlight dimmer switch signal to the steering sensor. |
| Steering Sensor | Receives light control switch signal and headlight dimmer switch signal from the turn signal switch and sends it to the main body ECU (multiplex network body ECU). |
SYSTEM CONTROL
| Function | Operation Condition |
|---|---|
|
*1: Except models for Middle East and Australia *2: Models for Middle East and Australia |
|
| Active | When all of the following conditions are met, the automatic high beam system is activated and the automatic high beam indicator light turns on:
·
The ignition switch is turned ON. ·
The light control switch is in the AUTO or HEAD position and the low beam headlights are on. ·
The headlight dimmer switch is in the high beam position. ·
The automatic high beam switch is ON. ·
The shift is in any position other than R. |
| High Beams on | When all of the following conditions are met, the automatic high beam system turns on the high beams after a short delay:
·
Vehicle speed is more than approximately 40 km/h (25 mph)*1. ·
Vehicle speed is more than approximately 30 km/h (19 mph)*2. ·
The area in front of the vehicle is dark. ·
No oncoming vehicles are present with the headlights on. ·
No preceding vehicles are present with the taillights on. ·
Few streetlights are present along the street ahead. |
| High Beams off | When any of the following conditions is met, the automatic high beam system turns off the high beams after a short delay:
·
Vehicle speed is less than approximately 30 km/h (19 mph)*1. ·
Vehicle speed is less than approximately 25 km/h (16 mph)*2. ·
The area in front of the vehicle is not dark. ·
An oncoming vehicle with headlights on is detected. ·
A preceding vehicle with taillights on is detected. ·
Several streetlights are present along the street ahead. |
FUNCTION
When passing an oncoming vehicle:
The automatic high beam system turns off the high beams before an oncoming vehicle comes within approximately 800 m (2625 ft.).
When an oncoming vehicle passes out of camera sensor range, the automatic high beam system turns the high beams on after a short delay.
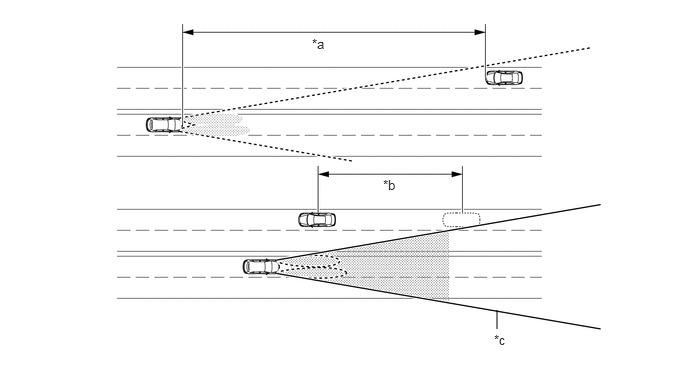
| *a | 800 m (2625 ft.) | *b | Delay |
| *c | Camera Sensor Angle | - | - |
- HINT:
- ·
The detection distance varies depending on detected objects.
·The timing of turning on and off the high beams varies depending on the intensity of oncoming (and preceding) vehicle lights.
When passing a preceding vehicle:
When approaching a preceding vehicle, the automatic high beam system turns off the high beams approximately 600 m (1969 ft.) before reaching it.
When a preceding vehicle passes out of camera sensor range, the automatic high beam system turns the high beams on after a short delay.
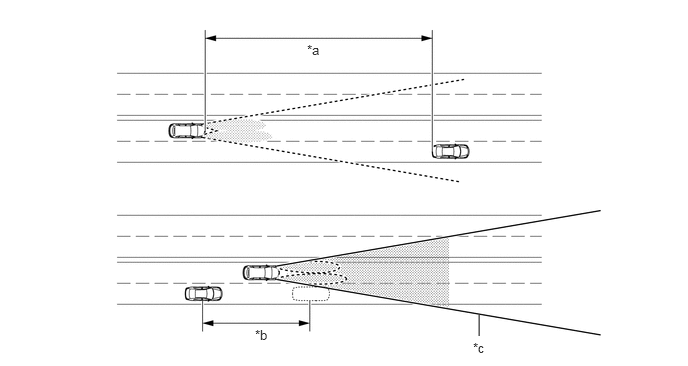
| *a | 600 m (1969 ft.) | *b | Delay |
| *c | Camera Sensor Angle | - | - |
- HINT:
-
The timing of turning on and off the high beams varies depending on the intensity of the preceding vehicle lights.
DIAGNOSIS
When the main body ECU (multiplex network body ECU) detects a malfunction in the automatic high beam control system, Diagnostic Trouble Codes (DTCs) are stored in memory.
The DTCs can be read using the Global TechStream (GTS). For details, refer to the Repair Manual.