GF2A TRANSFER / 4WD / AWD DYNAMIC TORQUE VECTORING AWD SYSTEM CONTROL FOUR WHEEL DRIVE CONTROL
FUNCTION OF MAIN COMPONENTS
| Component | Function | |
|---|---|---|
|
*1: Models without CVT *2: Models with CVT |
||
| 4WD ECU Assembly | Detects the driving conditions according to ECUs, sensors and switches and controls the solenoids inside the transfer and rear differential to optimally distribute drive force according to the current driving condition. | |
| Transfer | Front Dog Position Sensor | Detects the engagement status of the front dog clutch. |
| Front Dog Clutch Solenoid | Operates according output signals from the 4WD ECU assembly and engages the dog clutch. | |
| Differential | Propeller Shaft Revolution Sensor | Detects the speed of the propeller shaft. |
| Differential Temperature Sensor | Detects the oil temperature of the rear differential. | |
| Rear Dog Position Sensor | Detects the engagement status of the rear dog clutch. | |
| Rear Dog Clutch Solenoid | Operates according output signals from the 4WD ECU assembly and engages the dog clutch. | |
| Electro Magnetic Control Coupling Sub-Assembly LH | 4WD Linear Solenoid LH | Operates according to output signals from the 4WD ECU assembly and distributes drive force between the front and rear wheels and between the left and right rear wheels. |
| Electro Magnetic Control Coupling Sub-Assembly RH | 4WD Linear Solenoid RH | |
| Integration Control and Panel Assembly | ·
ROCK & DIRT Switch ·
NORMAL Switch ·
MUD & SAND Switch |
Switches between ROCK & DIRT mode, NORMAL mode and MUD & SAND mode. |
| Steering Sensor | Detects the direction and angle of the steering wheel. | |
| Speed Sensor | Detects the wheel speed of each wheel. | |
| Stop Light Switch Assembly | Detects the brake pedal depressing signal. | |
| Crank Position Sensor Assembly | Detects the engine speed and outputs it to the ECM. | |
| Throttle Position Sensor | Detects the throttle valve position and outputs it to the ECM. | |
| Park/Neutral Position Switch Assembly | Detects the shift position of the transaxle and outputs it to the ECM*1 or transmission control ECU*2. | |
| Airbag ECU (Airbag Sensor Assembly) | Yawrate Sensor | Detects the vehicle's yaw rate. |
| Deceleration Sensor | Detects the vehicle's longitudinal and lateral deceleration. | |
| ECM | Outputs signals such as the shift position signal*1, throttle position signal and engine speed signal to the 4WD ECU assembly. | |
| Transmission Control ECU*2 | Outputs shift position signals to the 4WD ECU assembly. | |
| Brake Actuator Assembly
·
Skid Control ECU |
·
Outputs signals such as the vehicle speed signal and brake pedal depressing signal to the 4WD ECU assembly. ·
Detects the parking brake operation condition and sends it to the Main Body ECU (Multiplex Network Body ECU) via CAN communication. |
|
| Main Body ECU (Multiplex Network Body ECU) | Outputs signals such as the parking brake operation condition to the 4WD ECU assembly. | |
| Combination Meter Assembly | Multi-information Display | Displays a warning message to inform or warn the driver of the system condition in accordance with signals from the 4WD ECU assembly. |
| ROCK & DIRT Indicator | Illuminates when ROCK & DIRT mode is selected. | |
| MUD & SAND Indicator | Illuminates when MUD & SAND mode is selected. | |
SYSTEM CONTROL
| Control | Function |
|---|---|
| Disconnect Control | Connects and disconnects the driveline according to a range of driving conditions. |
| Start Off Control | Performs control which distributes drive force to the rear wheels to ensure traction performance when starting off and avoid the tight corner braking phenomenon*, which occurs during cornering. |
| Normal Control | ·
Performs control which distributes drive force between the front and rear wheels and between the left and right rear wheels to ensure acceleration performance when driving straight ahead and cornering stability. ·
When a stable driving condition has been determined, disconnects the driveline or reduces drive force distribution to the rear wheels to improve fuel economy. |
| Cornering Control | Uses feed forward control, which is based on driver operation input, and yawrate feedback control, which is based on the vehicle status, to achieve the tracing performance desired by the driver. |
| VSC Cooperative Control | When accelerating during cornering on slippery surfaces, etc., the dynamic torque vectoring control 4WD/AWD system and VSC function cooperate to perform control which achieves smoother acceleration and higher stability compared to previous TRC and VSC functions. As a result, smooth acceleration during turning is made possible. |
| Braking Control | When braking, cancels 4WD/AWD to improve braking effectiveness. |
| Multi-terrain Select | Multi-terrain select is a function that switches to the optimal control for the road conditions, including 4WD/AWD control, brake control and motive force control, when the driver performs a switch operation to select an appropriate mode for the road conditions. Optimal control for the road conditions is automatically performed, maintaining driving performance and achieving superior off-road driveability. |
- HINT:
-
*: Tight corner braking phenomenon: a phenomenon in which a 4WD/AWD vehicle may lurch and decelerate due to a rotational speed difference between the front and rear wheels, such as during low-speed cornering in 4WD/AWD mode.
Start Off Control
The system ensures start-off performance by optimally distributing engine drive torque to the front and rear wheels.
To prevent the tight corner braking phenomenon from occurring during low-speed cornering, the system reduces the amount of torque distributed to the rear wheels.
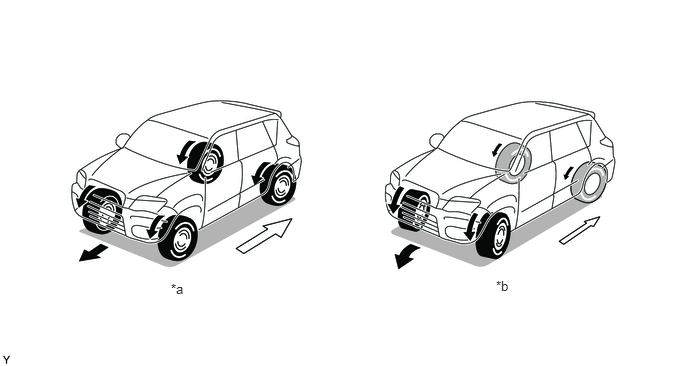
| *a | Straightline Driving | *b | Low-speed Cornering |

|
Torque Distribution to Rear Wheels | - | - |
Normal Control
During normal driving, when the system judges that the vehicle is traveling steadily, it reduces the amount of torque distribution to the rear wheels. This allows the vehicle to operate in conditions similar to front-wheel-drive, improving fuel economy.
The system optimizes torque distribution to the rear wheels to ensure both excellent straightline acceleration performance and excellent driving stability while cornering.
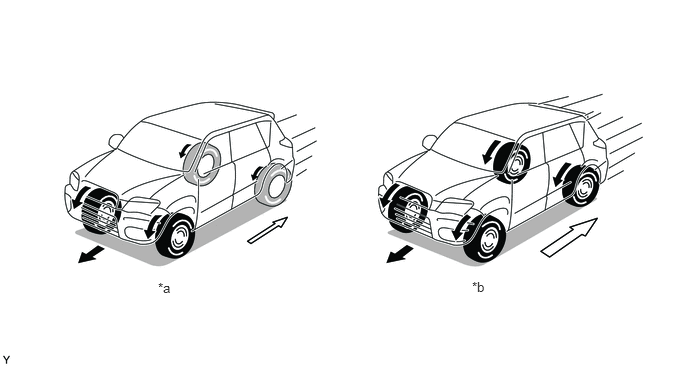
| *a | Steady Driving | *b | Straightline Acceleration |
|
|
Torque Distribution to Rear Wheels | - | - |
Cornering Control
Cornering control uses information such as the vehicle speed and steering angle to change the drive force distributed between the front and rear wheels and between the left and right rear wheels according to driving conditions, ensuring excellent driving stability and turning performance.
Feed forward control, which is based on driver operation input, and yawrate feedback control, which is based on the vehicle status, are used to correct vehicle oversteer and understeer and achieve the tracing performance desired by the driver.
Feed forward control is linked with driver steering wheel operations and distributes drive force between the front and rear wheels and between the left and right rear wheels to improve steering performance when entering a corner.
Yaw rate feedback control performs high-speed computation of the ideal yaw rate (calculated by the 4WD ECU assembly when the vehicle is in motion) and actual yaw rate, detects vehicle steering characteristics (oversteer or understeer), and performs optimal control to distribute drive force to the front/rear wheels and left/right rear wheels if required for correction.
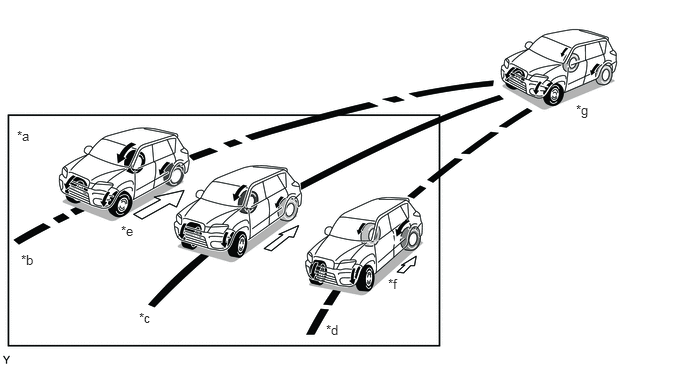
| *a | Yawrate Feedback Control | *b | Understeer Tendency |
| *c | Target Line | *d | Oversteer Tendency |
| *e | Drive Force Distribution to Rear Wheels Increased | *f | Drive Force Distribution to Rear Wheels Reduced |
| *g | Feed Forward Control | - | - |
FUNCTION
4WD/AWD Operation Condition Display
The operation condition of the 4WD/AWD system, which automatically operates according to the longitudinal acceleration, lateral acceleration and steering angle of the vehicle during driving, is shown on the multi-information display.
The user can recognize how the 4WD/AWD system is operating in response to various conditions, even on slippery roads. This contributes to improved safety while driving with the 4WD/AWD system.
The driver can operate the steering pad switch to select whether to display or hide the 4WD/AWD system operation condition.
| Multi-information Display | Outline |
|---|---|
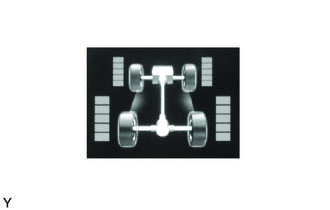
|
·
Drive force, which the 4WD/AWD system distributes to front and rear wheels, varies depending on the driving conditions. ·
The amount of drive force applied to each wheel is displayed in segments. ·
The number of displayed segments increases when the drive force applied to each wheel is large, and decreases when it is small. ·
When the drive force applied to the rear wheels is large, the capabilities of the 4WD/AWD system are being utilized in conditions that require start-off and driving performance. ·
When the drive force applied to the rear wheels is small, the system has determined that driving conditions are stable and the 4WD/AWD system is being restrained in order to improve fuel economy. ·
Longitudinal and lateral acceleration, which vary depending on the driving conditions, are indicated by the position of a sphere over concentric circles placed at the center of the vehicle. ·
The condition of the vehicle is indicated by the position of the sphere relative to the center of the concentric circles as shown below. Front: decelerating, rear: accelerating, right side: turning left, left side: turning right |
FAIL-SAFE
When there is a possibility of causing damage to the drivetrain due to a malfunction in the 4WD/AWD system or rough driving, the system displays a massage on the multi-information display to inform the driver and stops 4WD/AWD control.
| Vehicle Condition | Control | Combination Meter Assembly*A |
|---|---|---|
|
*A: Displayed message may vary depending on specifications. |
||
| 4WD/AWD system malfunction | 2WD driving
(control prohibited) |
·
4WD System Malfunction 2WD Mode Engaged Visit Your Dealer ·
AWD System Malfunction 2WD Mode Engaged Visit Your Dealer |
| 4WD/AWD excess driving (warning before AWD control is prohibited) | 4WD/AWD driving | ·
4WD System Overheated Switching to 2WD Mode ·
AWD System Overheated Switching to 2WD Mode |
| 4WD/AWD excess driving | 2WD driving
(control prohibited) |
·
4WD System Overheated 2WD Mode Engaged ·
AWD System Overheated 2WD Mode Engaged |
When the message is displayed on the multi-information display, perform the following procedures.
·
Decelerate the vehicle. ·
Stop the vehicle (idle the engine). |
When a stable system condition is determined, 4WD/AWD control automatically resumes.
DIAGNOSIS
The 4WD ECU assembly will also store a Diagnostic Trouble Code (DTC). The DTC can be accessed through the use of a Global TechStream (GTS). For details, refer to the Repair Manual.