P710 HYBRID TRANSMISSION / TRANSAXLE HYBRID TRANSAXLE SYSTEM DETAILS MG1 AND MG2
CONSTRUCTION
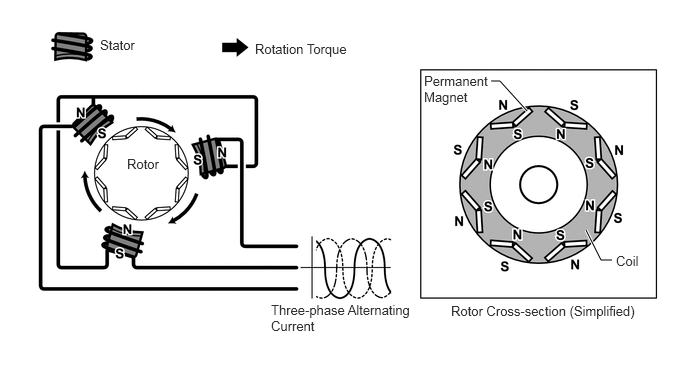
Compact, lightweight permanent magnet synchronous motors are used for the generator (MG1) and motor (MG2).
The generator (MG1) charges the HV battery and supplies electrical power to drive the motor (MG2). In addition, by regulating the amount of electrical power generated (varying the generator's rpm), the generator (MG1) effectively controls the continuously variable transmission function of the transaxle. The generator (MG1) also serves as the starter to start the engine.
The motor (MG2) assists engine output as an additional power source working in conjunction with the engine or operates separately depending on the situation, achieving excellent performance such as smooth starting and acceleration.
The motor generator ECU (MG ECU) receives signals from the hybrid vehicle control ECU and, based on these signals, switches the Insulated Gate Bipolar Transistors (IGBT) in the Intelligent Power Modules (IPM) to drive the generator (MG1) and motor (MG2).
When three-phase alternating current is applied to the three-phase winding of the stator coil, rotation of the magnetic field is created in the motor. This rotation of the magnetic field is controlled based on the rotation position and speed of the rotor to pull the permanent magnet located in the rotor towards the magnetic field, thereby producing torque. This torque, for all practical purposes, is proportional to the current, and the speed is controlled based on the frequency of the alternating current. Additionally, the rotation of the magnetic field and the angle of the rotor magnet are accurately controlled to efficiently generate high torque even at high speeds.
For the generator (MG1) and motor (MG2), the permanent magnets in the rotors are optimally located to efficiently use reluctance torque*. This amplifies the rotational force of the rotor, helping to enhance driving force.
- HINT:
-
*: Torque generated due to the changes in magnetic reluctance in the gap between the stator and rotor.
When generating power, rotation of the rotor creates a magnetic field, inducing current flow in the stator coil.
Rotation Sensor (Resolver Type)
The resolver type rotation sensors are compact, reliable sensors, which accurately detect the location of the magnets, which is necessary to efficiently control the generator (MG1) and motor (MG2).
The stator of a rotation sensor employs 3 coils as shown in the illustration. Output coil S and output coil C are arranged at a 90° angle to each other.
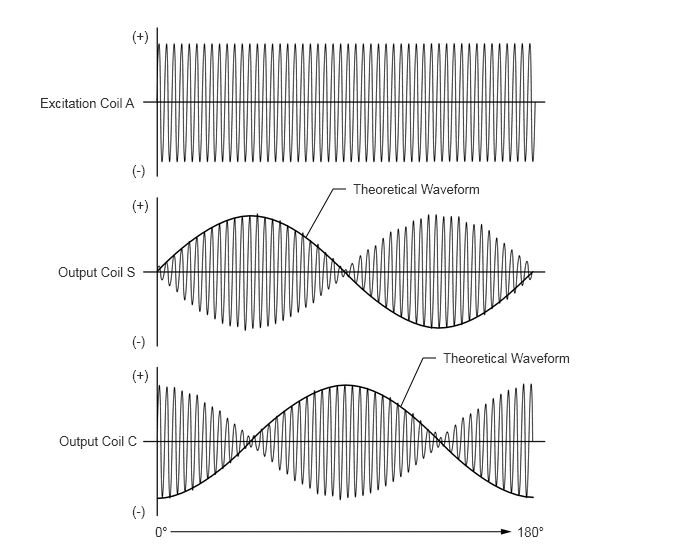
This sensor applies a certain amount of alternating current to excitation coil A so that a certain level of frequency is constantly applied to output coil S and output coil C regardless of the rotation speed of the rotor. Because the rotor is in an oval shape, the size of the gap between the stator and the rotor varies as the rotor rotates. As a result, peak values of the output waveforms of output coil S and output coil C fluctuate in response to the position of the rotor.
The Motor Generator ECU (MG ECU) detects the output coil peak values. It then connects those values to create a theoretical waveform. The absolute position of the rotor is estimated based on the difference between the values of output coil S and output coil C, the rotation direction is determined based on the phase difference of the theoretical waveforms of output coil S and output coil C, and the rotation speed is estimated based on the angular change of the rotor within a certain amount of time.
The following illustration shows waveforms of excitation coil A, output coil S and output coil C when the rotor rotates 180° in the positive (+) direction.
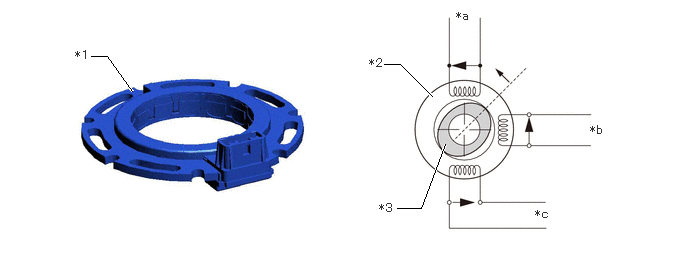
| *1 | Rotation Sensor (Resolver) | *2 | Stator |
| *3 | Rotor | - | - |
| *a | Excitation Coil A | *b | Output Coil S |
| *c | Output Coil C | - | - |
Temperature Sensor
A temperature sensor is provided for both the generator (MG1) and motor (MG2) to detect the stator temperature.
The hybrid vehicle control ECU performs hybrid system control based on the signal from these temperature sensors.