BRAKE CONTROL / DYNAMIC CONTROL SYSTEMS BRAKE CONTROL SYSTEM(for Gasoline Model) CONTROL VEHICLE STABILITY CONTROL (VSC)
SYSTEM CONTROL
The ABS and TRC systems help to ensure vehicle stability primarily when braking and accelerating, while the VSC system ensures directional stability of the vehicle. Depending on the road conditions, vehicle speed, sudden steering maneuvers and other outside influences, a strong understeer or oversteer condition can occur. In this situation, the VSC system controls the brake force of each wheel and the drive force of the drive wheels in order to minimize the understeer or oversteer and ensure vehicle stability.
For 4WD/AWD vehicles, the systems cooperate with the motive force distribution control of the dynamic torque control 4WD/AWD system*1 or dynamic torque vectoring AWD system*2 to achieve smoother and more stable driving.
*1: Models with GF1A type transfer
*2: Models with GF2A type transfer
The VSC system uses signals from various sensors such as the yawrate sensor to detect the vehicle condition in order to control the brake fluid pressure and drive force.
When the lateral grip of the tires is exceeded, the following situations can occur.
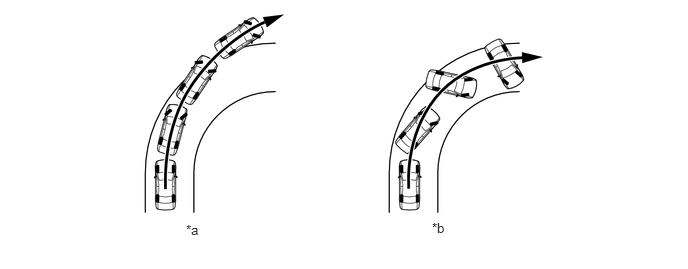
| *a | Understeer
·
The front wheels are slipping more than the rear |
*b | Oversteer
·
The rear wheels are slipping more than the front |
Strong Understeer Judgment
The skid control ECU determines if the vehicle is understeering based on the target yaw rate and the actual yaw rate. When the driver turns the steering wheel, if the actual yaw rate of the vehicle is less than the target yaw rate (determined based on the vehicle speed and steering wheel angle), the skid control ECU determines that the vehicle is understeering due to the insufficient turn rate.
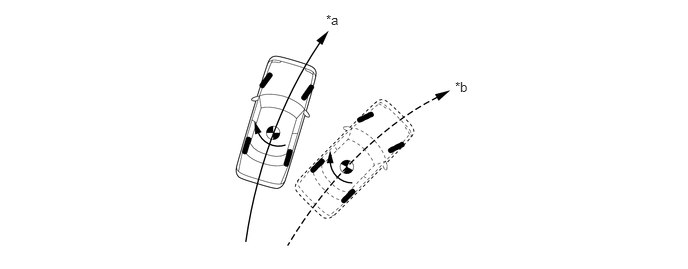
| *a | Actual Vehicle Path (Actual Yaw Rate) | *b | Vehicle Path Based on Target Yaw Rate |
Strong Oversteer Judgment
The skid control ECU determines if the vehicle is oversteering based on the slip angle and slip angular velocity. When the slip angle and slip angular velocity are large, the skid control ECU determines that the vehicle is oversteering.
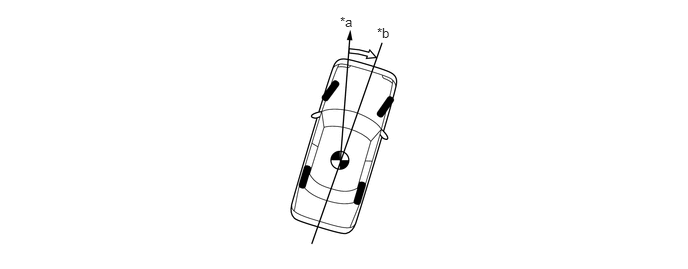
| *a | Path of Center of Gravity of Vehicle | *b | Longitudinal Centerline of Vehicle |

|
Slip Angle | - | - |
VSC Operation Method
When the skid control ECU determines that the vehicle is understeering, the skid control ECU limits the drive force and controls the brake force of each wheel in order to generate a moment that minimizes the understeer.
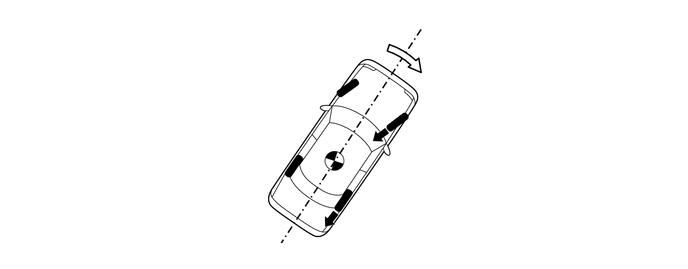

|
Brake Force |
|
Control Moment |
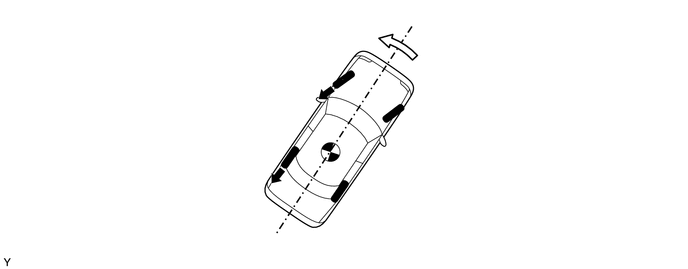
When the skid control ECU determines that the vehicle is oversteering, the skid control ECU primarily controls the brake force of the outer wheels to generate a moment toward the outside of the turn in order to minimize the oversteer. This control ensures stability of the vehicle while also reducing speed.
|
|
Brake Force |
|
Control Moment |