PARK ASSIST / MONITORING CLEARANCE SONAR SYSTEM CONTROL TOYOTA PARKING ASSIST-SENSOR CONTROL
OPERATION
The system performs obstacle detction when any of the following conditions are met.
Distance to critical collision obstacle is close:
Driving forward: When the gear is not in reverse and the vehicle speed is less than 5 km/h (3 mph), and distance to object in the front is less than 60 cm (1.97 ft.)
Engine Start: after bus sleep in standstill (vehicle speed is 0 km/h (0 mph)) with object in the front closer than 100 cm (3.28 ft.)
Driving backwards: When the gear is not in reverse and the vehicle is traveling backward, and the distance to an obstacle in the rear is less than 150 cm (4.92 ft.)
The reverse gear is engaged.
The system stops when any of the following conditions are met:
When the PARK button is pressed.
The deactivation of the function is not displayed separately.
Vehicle speed and distance traveled has exceeded the specified limits when in automatic mode.
The function has been deactivated using Toyota Supra Command.
FUNCTION
The clearance sonar system opens the parking panel automatically in the display if an obstacle is detected within the range of the ultrasonic sensors.
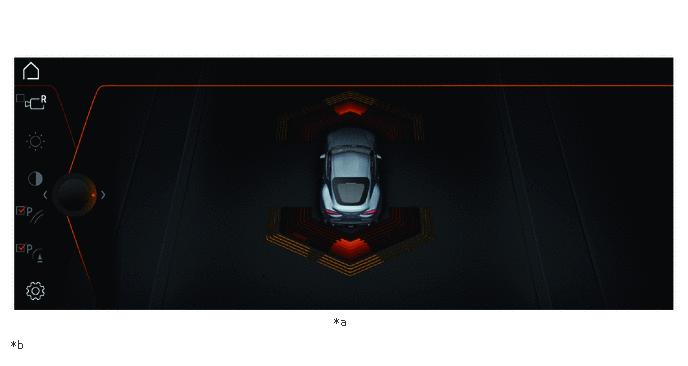
| *a | Clearance sonar display image | *b | The illustrations may differ from the actual display. |
The detected obstacles on the sides are tracked in accordance with the vehicle's motion. After start-up (of sleeping vehicle from bus idle state, for example unlocking and starting after an extended dormant time) or a brief dormant time, the obstacles will be discarded and an "Unclear" status is displayed.
When an obstacle is detected while the rear view camera is displayed, the information of the detected obstacle will be displayed on top of the rear view image.
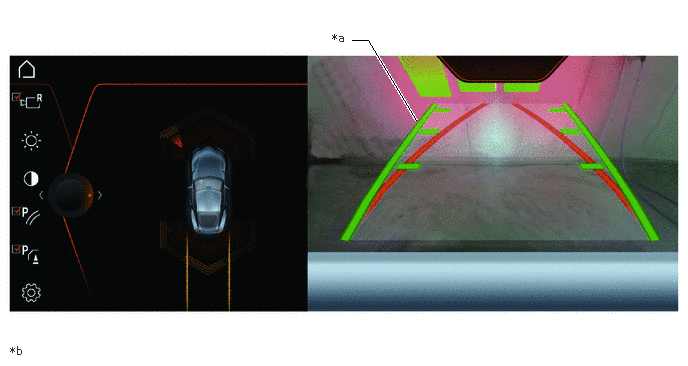
| *a | Rear view camera display image | *b | The illustrations may differ from the actual display. |
Buzzer volume can be changed via the Toyota Supra Command.