POWER STEERING SYSTEM (for Sedan) > DETAILS


FUNCTION OF MAIN COMPONENTS
  1. The main components of the EPS system are as follows:

    Component
    Function
    Steering Column Assembly
    Torque Sensor
    Detects the twist of the torsion bar, calculates the torque that is applied to the torsion bar by changing it into an electrical signal, and outputs this signal to the power steering ECU.
    Power steering motor
    Generates power assist in accordance with a signal received from the power steering ECU.
    Reduction Mechanism
    Reduces the speed of the power steering motor through the use of a worm gear and a wheel gear and transmits it to the column shaft.
    Power Steering ECU
    Actuates the power steering motor mounted on the steering column to provide power assist, based on the signals received from various sensors and vehicle speed.
    ECM
    Outputs engine speed signal to the power steering ECU.
    1. Brake Actuator Assembly
      1. Skid Control ECU*
    Outputs vehicle speed signal to the power steering ECU.
    Combination Meter Assembly
    Speedometer
    Outputs vehicle speed signal to the power steering ECU.
    EPS Warning Light
    In case of a malfunction in the system, turns ON the EPS warning light.
    *: Models With ABS with EBD System


SYSTEM CONTROL
  1. The power steering ECU receives signals from various sensors, judges the current vehicle condition, and determines the assist current to be applied to the power steering motor accordingly.

  2. In case a malfunction occurs in the system, the fail-safe function stops the output current and reverts the control to manual steering. At this time, a EPS warning light illuminates to alert the driver of the malfunction.

  3. The power steering ECU has the following controls:

    Control
    Outline
    Basic Control
    Calculates the assist current from the steering torque value and the vehicle speed, and actuates the motor.
    Inertia Compensation Control
    Ensures the starting movement of the motor when the driver starts to turn the steering wheel.
    Recovery Control
    During the short interval between the time the driver fully turns the steering wheel and the wheels try to recover, this control assists the recovery force.
    Damper Control
    Regulates the amount of assist when the driver turns the steering wheel while driving at high speeds, thus damping the changes in the yaw rate of the vehicle body.
    System Overheat Protection Control
    Estimates the motor temperature based on the amperage and the current duration. If the temperature exceeds the standard, it limits the amperage to prevent the motor from overheating.


CONSTRUCTION


  1. Steering Column Assembly


    1. A power steering motor, reduction mechanism, and torque sensor are mounted on the steering column.
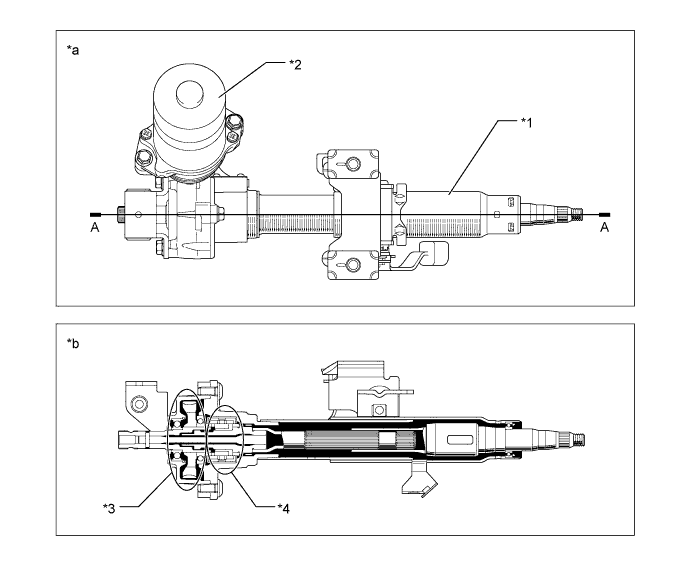

      X106101E01


      Text in Illustration 
      *1
      Steering Column Assembly
      *2
      Power Steering Motor
      *3
      Reduction Mechanism
      *4
      Torque Sensor
      *a
      Top View
      *b
      A-A Cross Section


  2. Power Steering Motor


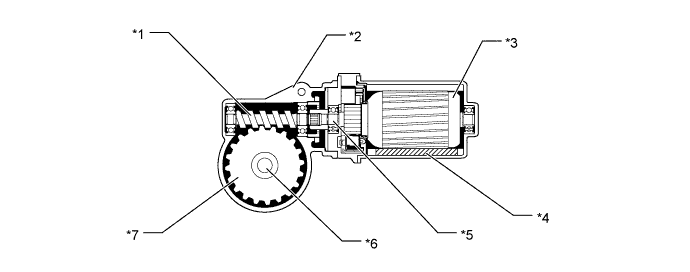
    1. The power steering motor consists of the rotor, stator, and motor shaft. The torque that is generated by the motor is transmitted via the joint to the worm gear. Then this torque is transmitted via the wheel gear to the column shaft.

      X106102E01


      Text in Illustration 
      *1
      Worm Gear
      *2
      Column Housing
      *3
      Rotor
      *4
      Stator
      *5
      Motor Shaft
      *6
      Column Shaft
      *7
      Wheel Gear
      -
      -


  3. Reduction Mechanism


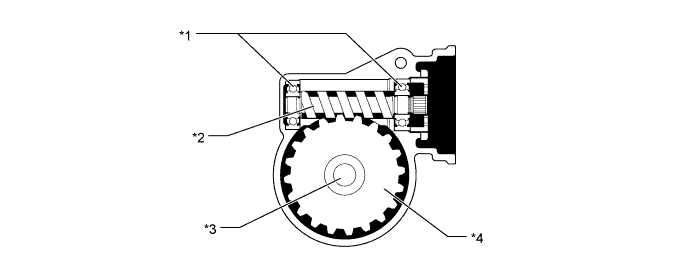
    1. This mechanism reduces the speed of the power steering motor via the worm gear and the wheel gear, and transmits it to the column shaft. The worm gear is supported by the ball bearings in order to reduce noise and frictions.

      X106103E01


      Text in Illustration 
      *1
      Ball Bearings
      *2
      Worm Gear
      *3
      Column Shaft
      *4
      Wheel Gear


  4. Torque Sensor

    1. The torque sensor detects the twist of the torsion bar, calculates the torque that is applied to the torsion bar by changing it into an electrical signal, and outputs this signal to the power steering ECU.

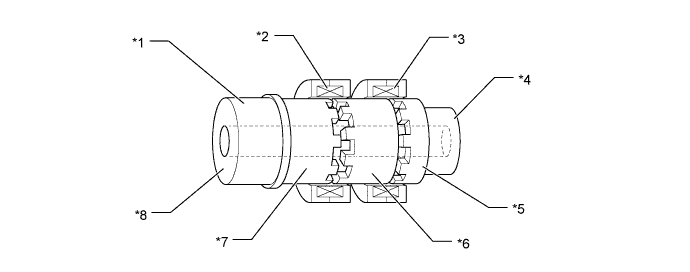
    2. Detection ring 1 and detection ring 2 are mounted on the input shaft, and detection ring 3 is mounted on the output shaft. The input shaft and the output shaft are joined by the torsion bar. A detection coil and a correction coil are placed on the outside of the respective detection rings to complete an excitation circuit without making a contact.

    3. The function of detection ring 1 and 2 is to correct temperature. They detect the temperature changes that occur in the correction coil and correct the deviation that is caused by the temperature changes.


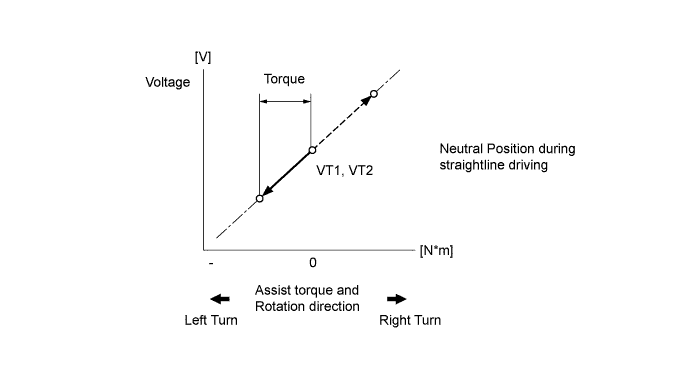
    4. The detection coil consists of a dual circuit that outputs two signals, VT1 and VT2. The ECU controls the assist amount based on these two signals and at the same time detects a sensor malfunction.

      X106104E01


      Text in Illustration 
      *1
      Torsion Bar
      *2
      Detection Coil
      *3
      Correction Coil
      *4
      Input Shaft
      *5
      Detection Ring 1
      *6
      Detection Ring 2
      *7
      Detection Ring 3
      *8
      Output Shaft

OPERATION
  1. Straightline Driving

    1. If the vehicle is driven straight and the driver does not turn the steering wheel, the specified voltage that is output at this time is determined by the power steering ECU to indicate the neutral position of the steering wheel. Therefore, it does not apply current to the Power Steering Motor.


  2. When Steering

    1. When a driver turns the steering wheel to the right or left, the twist that is created in the torsion bar creates a relative displacement between detection ring 2 and detection ring 3.

    2. This change is then converted into two electrical signals, VT1 and VT2, and sent to the power steering ECU. When the steering wheel is turned to the left, a voltage that is lower than the neutral is output as shown in the diagram below.


    3. The direction of the turn is thus detected according to these outputs. Furthermore, the amount of steering assist is determined by the magnitude of the output value.


      X106105E01


FAIL-SAFE
  1. Fail-safe operation modes are as follows:

    Item
    Control
    Torque Sensor System Malfunction
    Disables the assist.
    Motor Overheating
    Limits the assist force.
    Motor Short (including drive system malfunction)
    Disables the assist.
    Motor Overcurrent
    Disables the assist.
    Power steering ECU Internal Temperature Sensor Malfunction
    Limits the assist force.
    Power steering ECU System Malfunction
    Disables the assist.
    Vehicle Speed and Engine Speed Signals Malfunction
    Temporarily limits the assist, returning to normal control when normal conditions are reestablished.
    Power Supply Voltage Malfunction
    Temporarily limits the assist, returning to normal control when normal conditions are reestablished.


DIAGNOSIS
  1. If the power Steering ECU detects a problem in the EPS system, the warning light that corresponds to the function in which the malfunction has been detected lights up to alert the driver of the malfunction.

  2. At the same time, the DTCs (Diagnosis Trouble Codes) are stored in memory. The DTCs can be read by connecting the Techstream, or by connecting the SST (09843-18040) between the TC and CG terminals of the DLC3 and observing the blinking of the power steering warning light. For details, refer to the Repair Manual.