POWER ASSIST SYSTEMS POWER STEERING SYSTEM DETAILS TORQUE SENSOR
CONSTRUCTION
The torque sensor with Hall ICs is used.
The torque sensor is built into the steering column. A multipole magnet is mounted to the input shaft, and a yoke is mounted to the output shaft. The input and output shafts are joined by the torsion bar.
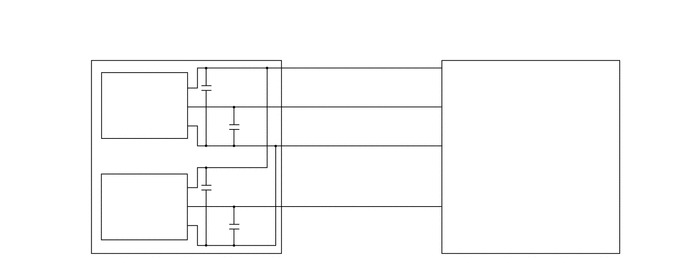
The magnetic convergence ring assembly contains Hall ICs, which face opposite to each other. The system detects the steering direction in accordance with the direction of the magnetic flux that the amount of change in the magnetic flux density based on the relative displacement of the multipole magnet and the yoke. The power steering ECU assembly monitors the torque sensor signals that are output by the two Hall ICs to detect malfunctions.
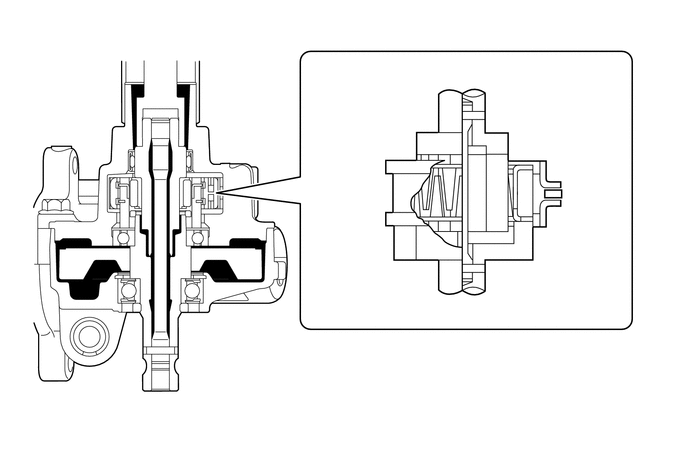
| *1 | Input Shaft | *2 | Output Shaft |
| *3 | Torsion Bar | *4 | Multipole Magnet |
| *5 | Hall IC | *6 | Yoke |
- NOTICE:
-
After replacing the steering column assembly, the steering gear assembly or the power steering ECU assembly, calibration of the torque sensor zero point is required. For details, refer to the Repair Manual.
OPERATION
Straightline Driving
If the vehicle is driven straight and the driver does not turn the steering wheel, the yoke is located in the center between the N and S poles of the multipole magnet. Thus, no magnetic flux passes between the Hall ICs. In this case, the Hall ICs output a specified voltage to the power steering ECU assembly, to indicate that the steering wheel is in the neutral position. Therefore, it does not apply current to the power steering motor.
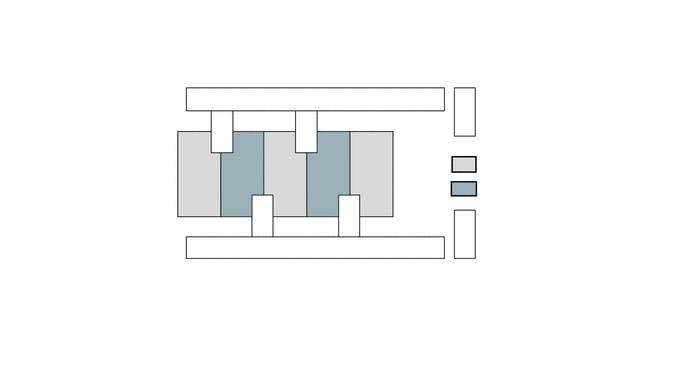
| *1 | Yoke | *2 | Multipole Magnet |
| *3 | Hall IC 1 | *4 | Hall IC 2 |
When Steering
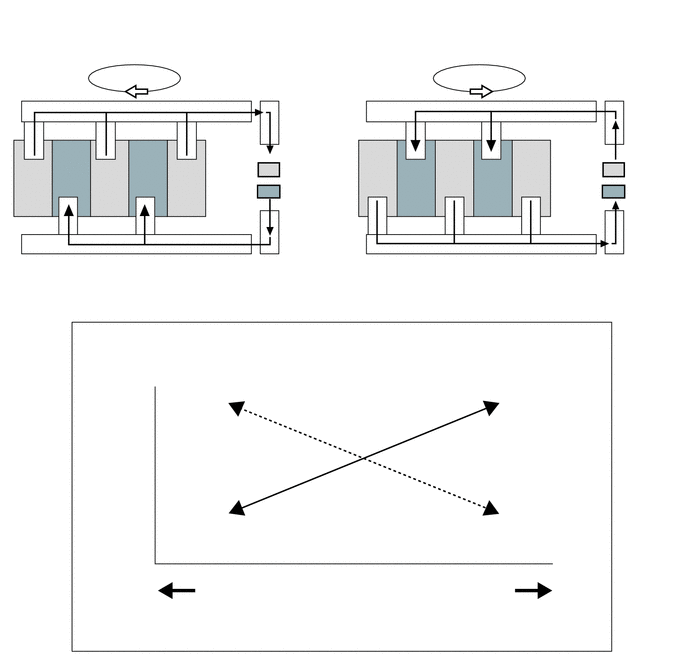
When a driver turns the steering wheel to the right or left, the twist that is created in the torsion bar creates a relative displacement between the multipole magnet and yoke.
At this time, the magnetic flux from the N to S pole of the multipole magnet passes between the Hall ICs. The system detects the steered direction of the steering wheel in accordance with the direction opposite to each other. As a result, the output characteristics of the 2 Hall ICs are constantly opposite each other. The system monitors the different outputs of these Hall ICs in order to detect malfunction.
The magnetic flux density becomes higher as it gets closer to the center of the respective pole. A Hall IC converts these magnetic flux fluctuations into voltage fluctuations, in order to transmit the turning torque of the steering wheel to the power steering ECU assembly.
The magnetic flux density becomes higher as it gets closer to the center of the respective pole. A Hall IC converts these magnetic flux fluctuations into voltage fluctuations, in order to transmit the turning torque of the steering wheel to the power steering ECU assembly.