SENSOR-MODE
DESCRIPTION
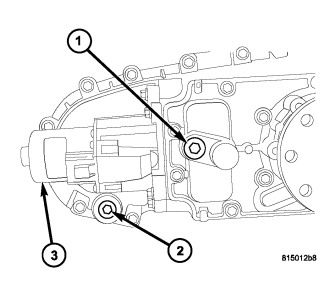
The transfer case mode sensor (3) provides the Final Drive Control Module (FDCM) feedback about the position of the transfer case. The sensor consists of a linear analog position sensor that converts the motor output shaft position into a DC signal. The sensor may rotate a full 360 degrees. The FDCM must supply 5VDC (+/- 0.5v) to the sensor whenever the FDCM is not in sleep mode and monitors the shift motor position. The sensor position is monitored when the ignition is in the RUN position and for 10 seconds after the ignition is shifted to the OFF position. The sensor is mechanically linked to the shaft of the cam which allows the transfer case to shift. The mode sensor will draw less than 20 mA of current during operation.
OPERATION
During normal vehicle operation, the Final Drive Control Module (FDCM) monitors the mode sensor outputs at least every 2 milliseconds when the shift motor is stationary or active.
NOTE: All the parameter voltages referred to in the following information are calibrated items in the controller software and are subject to change.
NOTE: For a further explanation of Phase 1 through 3 shifting, (Refer to 8 - ELECTRICAL/ELECTRONIC CONTROL MODULES/TRANSFER CASE CONTROL MODULE - OPERATION).
The following information describes the different mode sensor positions:- 4LOCK TARGET REGION - The position shall be considered 4LOCK if the voltage is greater than or equal to encoder_4LOCK_min Volts and it is also less than or equal to encoder_4LOCK_max Volts.
- AWD TARGET REGION - The position shall be considered AWD if the voltage is greater than or equal to encoder_AWD_min Volts and it is also less than or equal to encoder_AWD_max Volts.
- AWD SHIFT LIMIT - During Phase 2 and Phase 3 shifting, shifts may become unidirectional when a voltage is greater than or equal to encoder_AWD_min Volts has been reached.
The mode sensor position will be considered invalid by the FDCM if the voltage is greater than or equal to encoder_High_Range_Limit Volts or if it is less than or equal to encoder_Low_Range_Limit Volts.
If FDCM looses the encoder signal during a shift, the FDCM will respond with a shift back in the opposite direction of travel to first attempt to find the encoder signal. If the signal is not found, the FDCM will drive motor in AWD direction for 1 second.
Refer to MODE SENSOR VOLTAGES table for the mode sensor voltages.
| Parameter Name | Voltage |
| encoder_4LOW_Min | 4.19 |
| encoder_4LOW_Max | 4.35 |
| encoder_AWD_Min | 0.45 |
| encoder_AWD_Max | 0.55 |
| encoder_High_Range_Limit | 4.51 |
| encoder_Low_Range _Limit | 0.20 |