NETWORKING CAN COMMUNICATION SYSTEM SYSTEM DESCRIPTION
BRIEF DESCRIPTION
The Controller Area Network (CAN) is a serial data communication system for real time application. It is a vehicle multiplex communication system which has a high communication speed and the ability to detect malfunctions.
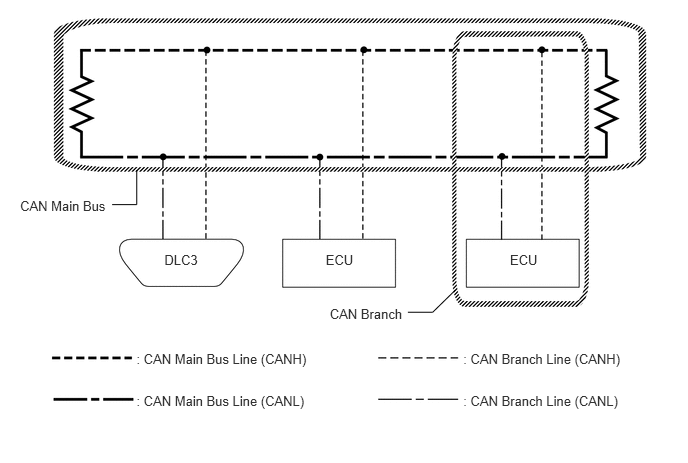
Using the CANH and CANL bus lines as a pair, CAN communication is performed using a voltage differential. (A base voltage is applied to the pair of lines and a voltage differential is created when communicating.)
Many ECUs or sensors installed on the vehicle operate by sharing information and communicating with each other.
The CAN has two resistors of 120 Ω which are necessary to enable communication.
DEFINITION OF TERMS
Main bus
The main bus is a wire harness between the two terminating resistors on the bus. This is the main bus in the CAN communication system.
Branch
A branch is a wire harness which diverges from the main bus to an ECU or sensor.
Terminating resistors
Two resistors of 120 Ω are installed in parallel across the ends of the CAN main bus lines. They are called terminating resistors. These resistors allow the changes of the voltage differential between the CAN bus lines to be accurately judged. To allow proper function of CAN communication, it is necessary to have both terminating resistors installed. Since the two resistors are installed in parallel, this results in a measurement of approximately 60 Ω.
ECUS OR SENSORS WHICH COMMUNICATE THROUGH CAN COMMUNICATION SYSTEM
V Bus
ECM
Brake booster with master cylinder assembly (Skid control ECU)
Main body ECU (Multiplex network body ECU)
Air conditioning amplifier assembly
Power steering ECU assembly
Smart key ECU assembly (Certification ECU)
Airbag sensor assembly
Steering sensor
Power management control ECU
Combination meter assembly
Navigation ECU sub-assembly*1
Radio and display receiver assembly*2
Headlight swivel ECU assembly (AFS ECU)*3
Navigation receiver assembly*6
Sub Bus 1*4
Main body ECU (Multiplex network body ECU)
Outer mirror control ECU assembly (for Driver side)
Outer mirror control ECU assembly (for Front passenger side)
Position control ECU and switch assembly (for Driver side)
Sub Bus 11
Power management control ECU
Blind spot monitor sensor LH*5
Blind spot monitor sensor RH*5
Rear television camera assembly*7
Sub Bus 15
ECM
Power management control ECU
Brake booster with master cylinder assembly (Skid control ECU)
- HINT:
-
*1: for Navigation Receiver Type with HDD
-
*2: for Radio and Display Type
-
*3: w/ Automatic High Beam System
-
*4: w/ Seat Position Memory System
-
*5: w/ Blind Spot Monitor System
-
*6: for Navigation Receiver Type without HDD
-
*7: w/ Parking Assist Monitor System without Parallel Parking Assist Function
CIRCUIT DESCRIPTION
The V bus, sub bus 1, sub bus 11 and sub bus 15 each have termination circuits with two resistors of 120 Ω.
TROUBLESHOOTING REMARKS
DTCs for the CAN communication system can be checked using the GTS. The DLC3 is connected to the CAN communication system, but no DTCs exist regarding problems in the DLC3 or the DLC3 branch lines. If there is a malfunction in the DLC3 or the DLC3 branch lines, ECUs on the CAN cannot output DTCs to the GTS.
Malfunctions in the CAN V bus (communication lines) can be checked by measuring the resistance between terminals of the DLC3. However, an open circuit in a branch line other than the DLC3 branch lines cannot be checked from the DLC3 (except the DLC3 branch lines).
- NOTICE:
-
Do not insert the tester probes directly into the DLC3. Be sure to use service wires.
DIAGNOSTIC TROUBLE CODES FOR CAN COMMUNICATION SYSTEM
- HINT:
-
See Diagnosis System.
-
Click herePower Source / Network>NETWORKING>CAN COMMUNICATION SYSTEM>DIAGNOSIS SYSTEM
HOW TO DISTINGUISH CONNECTOR OF CAN JUNCTION CONNECTOR
In the CAN communication system, the shape of connectors connected to the CAN junction connector which has an earth terminal is the same. The connectors connected to the CAN junction connector can be distinguished by the colors of the bus lines and the connecting side of the junction connector.
- HINT:
-
See Terminals of ECU for bus line color or the shape of connectors.
-
Click herePower Source / Network>NETWORKING>CAN COMMUNICATION SYSTEM>TERMINALS OF ECU