NETWORKING MULTIPLEX COMMUNICATION SYSTEM GENERAL/CONTROL/DETAILS GENERAL
OUTLINE
The multiplex communication system of the new models uses 2 communication protocols described below in order to achieve a slimmer wiring harness configuration.
Controller Area Network (CAN): There are 2 types, they are categorized based on the communication speed: High Speed (HS) CAN and Medium Speed (MS) CAN. The HS-CAN is used for the powertrain, chassis, and body electrical system, while the MS-CAN is used for the body electrical system.
AVC-LAN (Audio Visual Communication - Local Area Network): It is used only when the vehicle is equipped with both a radio and player with display and a rear seat entertainment ECU.
There are 2 CAN buses, the HS-CAN (CAN No. 1 bus) and MS-CAN (MS bus). The main body ECU has a gateway function and is used to connect the buses, thus enabling communication among the different buses.
Along with the use of CAN in the power train, chassis, and body electrical system, the BEAN (Body Electronics Area Network) that was used in the body electrical system of the previous models has been discontinued.
A customized body electronics system is used, enabling the control functions of the ECUs to be set using an intelligent tester II.
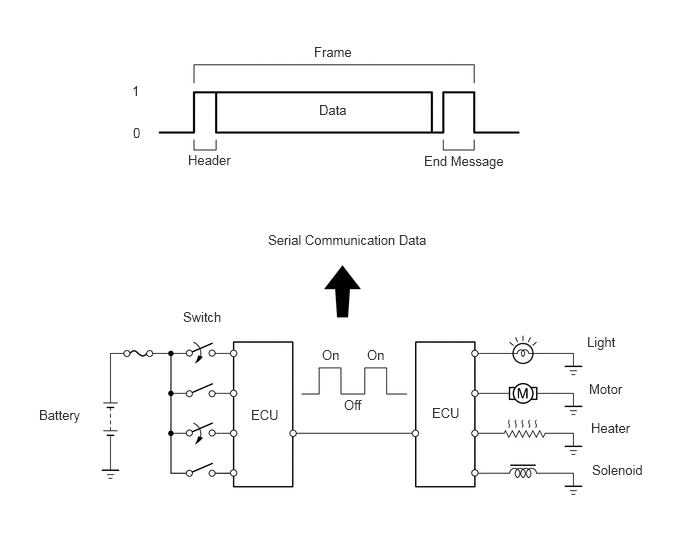
Multiplex communication uses serial communication data that consists of bits and frames in order to exchange information among the various ECUs. This allows a reduction of the amount of wiring on the vehicle.
A bit is the basic unit of communication that is used to represent the information. A bit is represented by binary values of "0" or "1".
A frame is a body of data that is transmitted together. A frame contains a header that indicates the beginning, and an end message that indicates the end.
DIFFERENCES AMONG CAN, AVC-LAN AND BEAN
The protocols, which are the rules for establishing data communication, differ among the CAN, AVC-LAN and BEAN. If ECUs use different types of data such as with different communication speed, communication wire, and signals, they will be unable to understand each other. Therefore, protocols (rules) must be established among them.
One of the features of CAN is a faster communication speed than AVC-LAN and BEAN. Thus, it can transmit and receive a greater amount of data in a shorter time than the other protocols. This enables the accurate transmission and reception of data in the power train and chassis control system, which requires a great amount of data to be transmitted and received in a short time.
|
*: bps: abbreviation for "Bits Per Second", indicating the number of bits that can be transmitted per second. |
|||
| Protocol | CAN
(ISO Standard) |
AVC-LAN
(TOYOTA Original) |
BEAN
(TOYOTA Original) |
| Communication Speed | 500 k bps*/HS-CAN
250 k bps*/MS-CAN (Max. 1 Mbps) |
Max. 17.8 kbps* | Max. 10 kbps* |
| Communication Wire | Twisted-pair Wire | Twisted-pair Wire | AV Single Wire |
| Drive Type | Differential Voltage Drive | Differential Voltage Drive | Single Wire Voltage Drive |
| Data Length | 1-8 Byte (Variable) | 0-32 Byte (Variable) | 1-11 Byte (Variable) |
Communication Wire
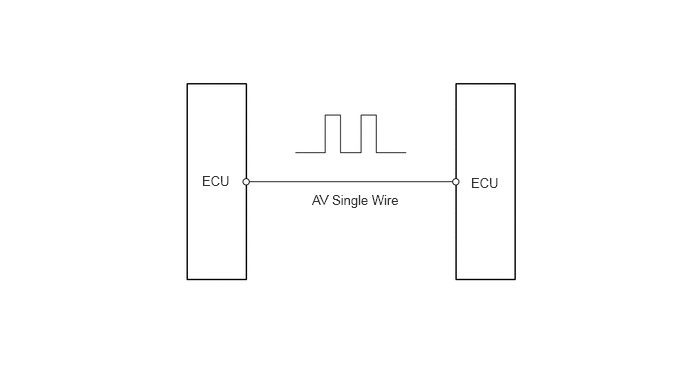
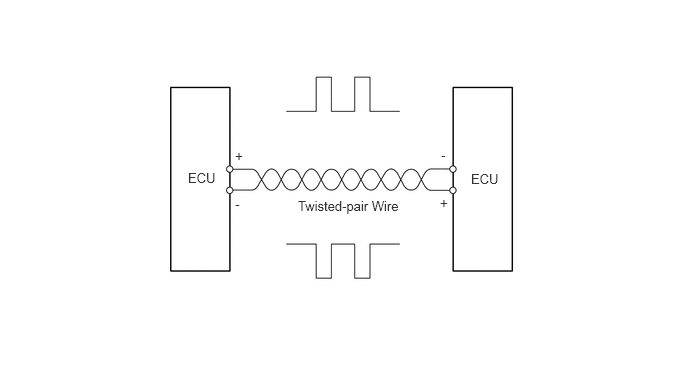
A single, AV (Automobile Vinyl) wire is used for BEAN communication. A twisted-pair wire is used for CAN and AVC-LAN communication.
| Communication Wire | Outline | |
|---|---|---|
| Twisted-pair Wire for CAN | 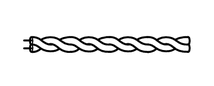
|
In this communication wire, a pair of lines are twisted together and covered with insulation. The communication is driven by applying positive (+) and negative (-) voltage to the two lines in order to send a single signal.
This system, which is called a "Differential Voltage Drive", can reduce noise. |
| Twisted-pair Wire for AVC-LAN | 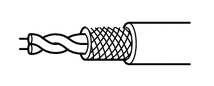
|
|
| AV Single Wire | 
|
This is a lightweight single communication wire that consists of a single core line surrounded by insulation. Voltage is applied to this line in order to drive the communication, and this system is called a "Single Wire Voltage Drive". |
MAJOR DIFFERENCE
The brake actuator assembly (skid control ECU) has been discontinued on models without VSC.