BODY ELECTRICAL DYNAMIC RADAR CRUISE CONTROL SYSTEM GENERAL/CONTROL/DETAILS GENERAL
General
The dynamic radar cruise control system has 2 cruise control modes: constant speed control mode and vehicle-to-vehicle distance control mode.
The cruise control switch is used for switching between the 2 modes. The mode in which the cruise control system starts is the vehicle-to-vehicle distance control mode.
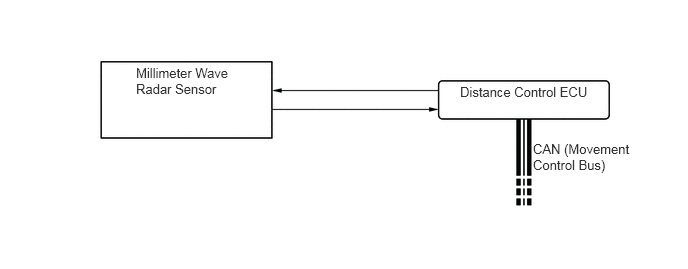
The dynamic radar cruise control system is controlled by the distance control ECU, millimeter wave radar sensor and ECM.
The combination meter informs the driver of the control conditions.
| Mode | Outline |
|---|---|
| Constant Speed Control Mode | The constant speed control mode is the same as in the cruise control system. |
| Vehicle-to-vehicle Distance Control Mode | In the vehicle-to-vehicle distance control mode, the system recognizes and determines the lane in which the driver's own vehicle and the vehicle ahead are traveling. Thus, the system is able to maintain the proper vehicle-to-vehicle distance in accordance with the vehicle speed, and allows the vehicle to be driven under follow-up control.
·
The driver can operate the distance control switch on the steering wheel to select the vehicle-to-vehicle distance in three stages: long, middle and short. ·
This mode consists mainly of four controls: constant speed control, deceleration control, follow-up control and acceleration control. ·
The illustrations below show control examples while the driver's own vehicle is operating at 100 km/h (62 mph) and the vehicle ahead is operating at 80 km/h (50 mph). ·
The distance control ECU increases and decreases the vehicle speed by controlling the engine and brakes through transmitting the target acceleration rate, target deceleration rate and brake request signals to the skid control ECU and ECM. |
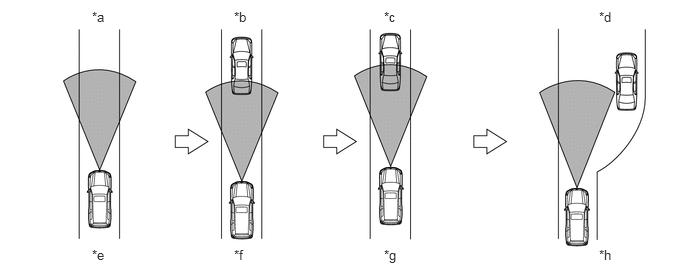
| *a | Constant Speed Control | *b | Deceleration Control |
| *c | Follow-up Control | *d | Acceleration Control |
| *e | 100 km/h (62 mph) | *f | 100 km/h (62 mph) → 80 km/h (50 mph) |
| *g | 80 km/h (50 mph) | *h | 80 km/h (50 mph) → 100 km/h (62 mph ) |
- HINT:
-
When either the distance control ECU or the ECM is replaced, the millimeter wave radar sensor information stored in the replaced ECU must be initialized. For details, see the Repair Manual.
As in the cruise control system, the constant speed control mode is controlled by the distance control ECU, which outputs signals to the skid control ECU and the ECM.
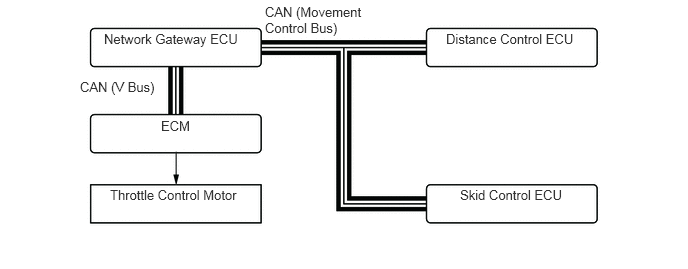
The vehicle-to-vehicle distance control mode is controlled by the millimeter wave radar sensor and distance control ECU. Thus, the signals are output to the actuators and the ECU while exchanging data as indicated below: