NAVIGATION / MULTI INFO DISPLAY NAVIGATION SYSTEM SYSTEM DESCRIPTION
NAVIGATION SYSTEM OUTLINE
Vehicle position tracking methods:
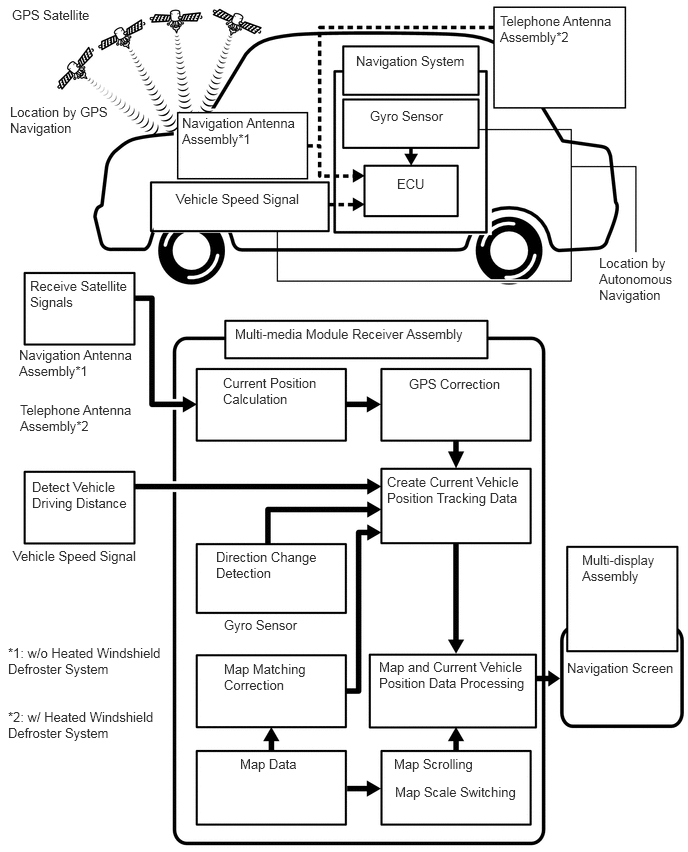
It is essential that the navigation system correctly tracks the current vehicle position and displays it on the map. There are 2 methods to track the current vehicle position: autonomous (dead reckoning) and GPS* (satellite) navigation. Both navigation methods are used in conjunction with each other.
*: GPS (Global Positioning System)
| Operation | Description |
|---|---|
| Vehicle Position Calculation | The multi-media module receiver assembly calculates the current vehicle position (direction and current position) using the direction deviation signal from the gyro sensor and driving distance signal from the vehicle speed sensor and creates the driving route. |
| Map Display Processing | The multi-media module receiver assembly processes the vehicle position data, vehicle driving track and map data from the SD card. |
| Map Matching | The map data from the SD card is compared to the vehicle position and driving track data. Then, the vehicle position is matched with the nearest road. |
| GPS Correction | The vehicle position is matched to the position measured by the GPS. Then, the GPS measurement position data is compared with the vehicle position and driving track data. If the position is very different, the GPS measurement position is used. |
| Distance Correction | The vehicle speed signal includes the error caused by tire wear and slippage between the tires and road surface. Distance correction is performed to account for this. The multi-media module receiver assembly automatically offsets the signal to make up for the difference between it and the distance data of the map. The offset is automatically updated. |
- HINT:
-
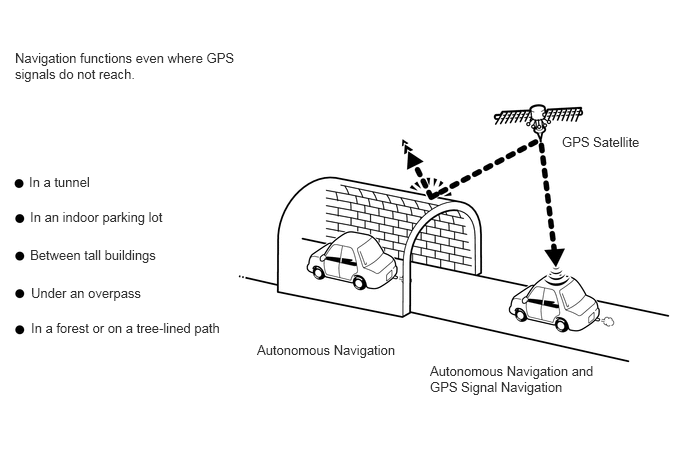
The combination of autonomous and GPS navigation makes it possible to display the vehicle position even when the vehicle is in places where GPS signals cannot be received. When only autonomous navigation is used, however, the mapping accuracy may slightly decrease.
Autonomous navigation
This method determines the relative vehicle position based on the driving track determined by the gyro located in the multi-media module receiver assembly and the vehicle speed signal.
Gyro sensor
Used to calculate the direction by detecting angular velocity. It is located in the multi-media module receiver assembly.
Vehicle speed signal
Used to calculate the vehicle driving distance.
GPS* navigation (Satellite navigation)
This method detects the absolute vehicle position using radio waves from GPS satellites.
*: GPS satellites were launched by the U.S. Department of Defense for military purposes.
| Number of Satellites | Measurement | Description |
|---|---|---|
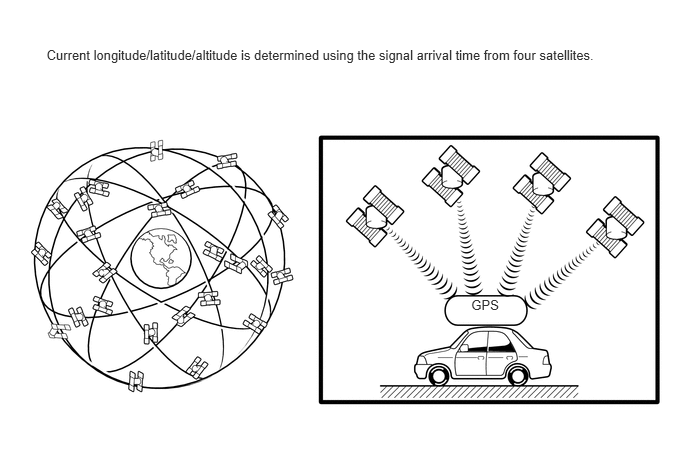
| 2 or less | Measurement is impossible | Vehicle position cannot be obtained because the number of satellites is not enough. |
| 3 | 2-dimensional measurement is possible | Vehicle position is obtained based on the current longitude and latitude. (This is less precise than 3-dimensional measurement.) |
| 4 | 3-dimensional measurement is possible | Vehicle position is obtained based on the current longitude, latitude and altitude. |
Map matching
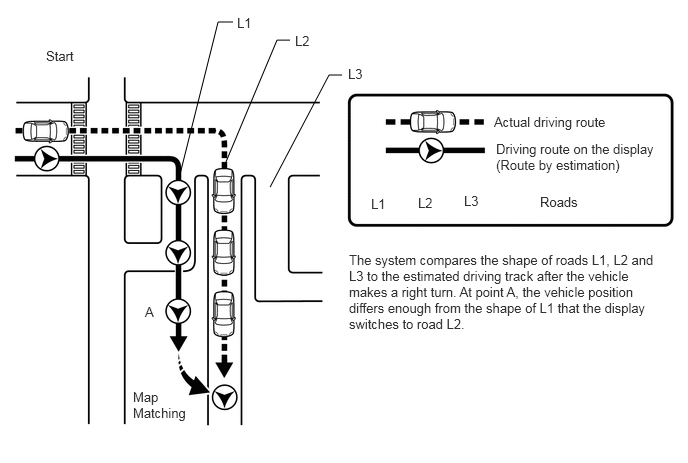
The current driving route is calculated by autonomous navigation (according to the gyro sensor and vehicle speed signal) and GPS navigation. This information is then compared with possible road shapes from the map data in the SD card and the vehicle position is set onto the most appropriate road.
Touch switch
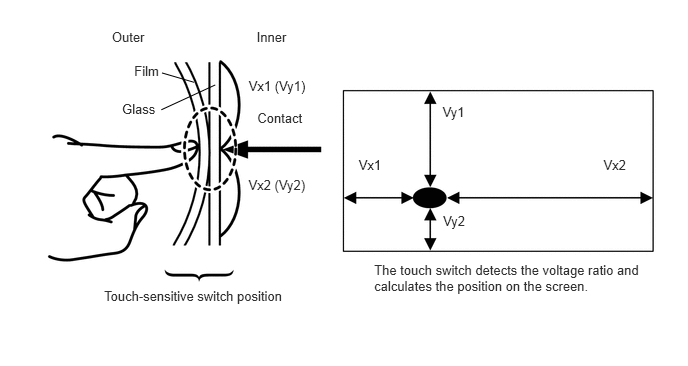
Touch switches are touch-sensitive (interactive) switches operated by touching the screen. When a switch is pressed, the outer film bends in to contact the inner glass at the pressed position. By doing this, the voltage ratio is measured and the pressed position is detected.
DISC PLAYER OUTLINE
A disc player uses a laser pickup to read digital signals recorded on a disc. By converting the digital signals to analog, it can play music, video and audio.
- CAUTION:
-
Do not look directly at the laser pickup because the disc player uses an invisible laser beam. Be sure to operate the player only as instructed.
- NOTICE:
- ·
Do not disassemble any part of the disc player.
·Do not apply oil to the disc player.
·Do not insert anything but a disc into the disc player.
This player can play only audio CDs, CD-Rs (CD-Recordable) and CD-RWs (CD-ReWritable) that have any of the following marks:
This player can play only VCD videos that have any of the following marks (w/ VCD Player)
This player can play only DVD videos that have any of the following marks:
This player can play only DVD-Rs (DVD-Recordable) and DVD-RWs (DVD-ReWritable) that were recorded in video format and that have any of the following marks:
The following products may not be playable on your player.
SACD
DTS CD
Copy-protected CD
Super Video CD
DVD audio
DVD-RAM
Precautions for use of discs
- NOTICE:
- ·
CD-Rs, CD-RWs, DVD-Rs (DVD-Recordable) and DVD-RWs (DVD-ReWritable) may not be played depending on the recording conditions or characteristics of the discs, or due to damage, dirt or deterioration caused by leaving the discs in the cabin for a long time.
·Unfinalized CD-Rs, CD-RWs, DVD-Rs (DVD-Recordable) and DVD-RWs (DVD-ReWritable) cannot be played.
·CD-Rs, CD-RWs, DVD-Rs (DVD-Recordable) and DVD-RWs (DVD-ReWritable) are more easily affected by a hot and humid environment than discs used for normal audio CDs. For this reason, some CD-Rs and CD-RWs may not play.
·If there are fingerprints or scratches on a disc, the disc may not play or the disc may skip.
·Some CD-Rs, CD-RWs, DVD-Rs (DVD-Recordable) and DVD-RWs (DVD-ReWritable) may deteriorate if they are left in the cabin for a long time.
·Keep CD-Rs, CD-RWs, DVD-Rs (DVD-Recordable) and DVD-RWs (DVD-ReWritable) in an opaque case.
·SECAM color television standard discs cannot be played.
·DualDiscs that mate DVD recorded material on one side with CD digital audio material on the other cannot be played.
·Keep the discs away from dirt. Be careful not to damage the discs or leave fingerprints on them.
·Hold discs by the outer edge and center hole with the label side up.
·Leaving the disc exposed halfway out of the slot for a long time after pressing the disc eject button may cause deformation of the disc, making the disc unusable.
·If discs have adhesive tape, stickers, disc labels or any traces of such labels attached, the discs may not be ejected or player malfunctions may result.
·Keep the discs away from direct sunlight. (Exposure to direct sunlight may cause deformation of the disc, making the disc unusable.)
·Do not use odd-shaped discs because these may cause player malfunctions.
·Do not use discs whose recording portion is transparent or translucent because they may not be inserted, ejected or played normally.
·Use only 4.7 in. (12 cm) discs.
·Do not use 3 in. (8 cm) CDs either with or without adaptors.
- HINT:
- ·
When it is cold or raining, if the windows fog up, mist and condensation may form in the player. In such cases, the disc may skip or stop in the middle of play. Ventilate or dehumidify the cabin for a while before using the player.
·The disc may skip if the player experiences strong vibrations when the vehicle is driven on rough roads or similar uneven surfaces.
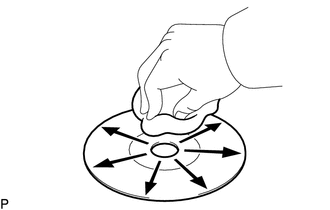
Cleaning
- NOTICE:
-
Do not use a lens cleaner because it may cause a malfunction in the pickup portion of the player.
If dirt is on the disc surface, wipe it clean with a soft dry cloth such as an eyeglass cleaner for plastic lenses from the inside to the outside in a radial direction.
- NOTICE:
- ·
Pressing on the disc by hand or rubbing the disc with a hard cloth may scratch the disc surface.
·Use of solvents such as record spray, antistatic agents, alcohol, benzine, thinners or a chemical cloth may cause damage to the disc, making the disc unusable.
"Bluetooth" OUTLINE
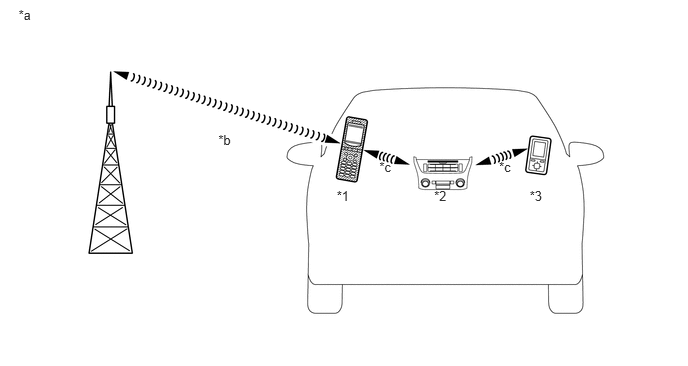
| *1 | Cellular Phone ("Bluetooth" compatible type) | *2 | Multi-media Module Receiver Assembly (Built-in "Bluetooth" receiver antenna) |
| *3 | Portable Audio Player ("Bluetooth" compatible type) | - | - |
| *a | Example | *b | Cellular Network |
| *c | "Bluetooth" Wireless Connection | - | - |
"Bluetooth" is a trademark owned by Bluetooth SIG, Inc.
"Bluetooth" is a wireless connection technology that uses the 2.4 GHz frequency band.
- HINT:
-
The communication performance of "Bluetooth" may vary depending on obstructions or radio wave conditions between communication devices, electromagnetic radiation, communication device sensitivity or antenna capacity.
Hands-free function
The "Bluetooth" built-in multi-media module receiver assembly and a "Bluetooth" compatible cellular phone* can be connected using a "Bluetooth" wireless connection. This enables the use of the hands-free function on the cellular phone even if the phone is in a pocket or bag. For this reason, it is not necessary to use a connector or cable to connect the cellular phone.
*: Some versions of "Bluetooth" compatible cellular phones may not function.
Compatible hands-free devices
| Required "Bluetooth" specifications | Ver. 2.0 or higher (Ver. 3.0 + EDR or higher recommended) |
| Compatible profiles | ·
HFP (Hands-Free Profile) Ver. 1.0 or higher (Ver. 1.6 or higher recommended)*1 ·
OPP (Object Push Profile) Ver. 1.1 or higher*1 ·
PBAP (Phone Book Access Profile) Ver. 1.0 or higher (Ver. 1.1 or higher recommended)*1 ·
MAP (Message Access Profile) Ver. 1.0 or higher*2 ·
SPP (Serial Port Profile) Ver. 1.1 or higher*3 ·
PAN (Personal Area Networking) Ver. 1.0 or higher*4 ·
DUN (Dial-Up Networking Profile) Ver. 1.1 or higher*5 |
| Maximum number of handsfree devices that can be registered (including audio devices) | 5 |
*1: This profile is necessary when using the hands-free function.
*2: This profile is necessary when using the message function (w/ SMS/MMS/e-mail Function).
*3: This profile is necessary when using the Toyota Link function (w/ Toyota Link Function).
*4: This profile is necessary when using the connected services function (w/ Connected Services).
*5: This profile is necessary when using the connected services function (w/ Connected Services).
- HINT:
-
The amount of remaining battery charge displayed on the multi-media module receiver assembly may be different from that of the "Bluetooth" device.
"Bluetooth" audio function
The "Bluetooth" built-in multi-media module receiver assembly and a "Bluetooth" compatible portable audio player* can be connected using a "Bluetooth" wireless connection. This enables files stored in the portable audio player to be heard from the vehicle speakers. In addition, operations such as play/stop can be performed directly from the multi-media module receiver assembly.
*: Some versions of "Bluetooth" compatible audio players may not be able to operate the "Bluetooth" function, or music may play, but functions available using the multi-media module receiver assembly may be limited.
Compatible "Bluetooth" audio devices
| Required "Bluetooth" specifications | Ver. 2.0 or higher (Ver. 3.0 + EDR or higher recommended) |
| Compatible profiles | ·
A2DP (Advanced Audio Distribution Profile) Ver. 1.0 or higher (Ver. 1.2 or higher recommended) ·
AVRCP (Audio/Video Remote Control Profile) Ver. 1.0 or higher (Ver. 1.4 or higher recommended) |
| Maximum number of audio devices that can be registered (including hands-free devices) | 5 |
- HINT:
-
The amount of remaining battery charge displayed on the multi-media module receiver assembly may be different from that of the "Bluetooth" device.
"Wi-Fi" OUTLINE (w/ "Wi-Fi" Function)
"Wi-Fi" is a worldwide wireless communication standard widely used as a short range communication tool.
"Wi-Fi" is a trademark owned by Wi-Fi Alliance, a non-profit industry association.
The multi-media module receiver assembly uses the 2.4 GHz frequency band for "Wi-Fi" communication.
- HINT:
-
The communication performance of "Wi-Fi" may vary depending on obstructions or radio wave conditions between communication devices, electromagnetic radiation, communication device sensitivity or antenna capacity.
TOYOTA LINK FUNCTION OUTLINE (w/ Toyota Link Function)
Enables the usable content of a cellular phone to be displayed on and operated from the multi-display assembly screen. As "Bluetooth" communication is used for the communication between a cellular phone and the multi-media module receiver assembly, before using the Toyota Link function on the navigation system, the cellular phone needs to be registered with the navigation system as a "Bluetooth" device. For details regarding Toyota Link, applications and compatible phones, refer to http:// www.toyota.com.au/.
CONNECTED SERVICES OUTLINE (w/ Connected Services)
The following services are available by connecting the navigation system to Toyota's portal site via the internet using a cellular phone or "Wi-Fi" network.
Online search: New establishments, such as restaurants, bars, etc., that are not registered in the navigation system can be set as a destination.
Importing memory points: Establishments that were searched for using a personal computer can be set as a destination and can be registered as memory points.
- HINT:
- ·
For known compatible phones, refer to http://www.my.toyota.eu.
·It is necessary to agree to the terms of service for the search engine on http:// www.my.toyota.eu. Failure to do so may cause problems such as not being able to select the search engine or the screen not transferring to the next screen when "Online search" is selected.
·Connected services are available only on a multi-media module receiver assembly that has had its identification code registered when the account was created.
·Search results may not be displayed if the target establishment is not in the data supplied by the provider or in the map data of the navigation system.
·As the information for a destination set using the connected services is supplied by the provider, the navigation system may guide to a location that deviates from the actual destination.
TRAFFIC AND PARKING INFORMATION FUNCTION OUTLINE (w/ Connected Services)
Traffic information, traffic prediction information and parking lot information can be viewed. There are 3 methods to receive the above information.
| Priority | Method | Information |
|---|---|---|
| 1st | Internet by using a cellular phone or "Wi-Fi" network | ·
TPEG-TEC (Traffic Event Compact) ·
TPEG-TFP (Traffic Flow Prediction) ·
TPEG-TKI (Live Parking Information) |
| 2nd | DAB | |
| 3rd | FM | RDS-TMC (Radio Data System-Traffic Message Channel) |
- HINT:
- ·
When RDS-TMC information and TPEG information can be received, TPEG information will be given priority.
·When the source for traffic information is switched between RDS-TMC information and TPEG information, traffic information displayed on the map may change.
·When the vehicle enters an area where TPEG information can be received, TPEG information can be received only after the vehicle has been driven for 1 km (0.6 miles) or more in the coverage area.
·Traffic information is displayed only on a map with a scale of 13 km (8 miles) or less.
·The traffic information display range is 30 km (18 miles) from the current position and next destination for city roads, and 100 km (62 miles) from the current position for highways.
·Parking information is displayed only on a map with a scale of 1 km (0.5 miles) or less.
·The parking information display range is 10 km (6 miles) from the current position and next destination.
·Detoured route search activates only when traffic information within 200 km (124 miles) exists.
·If there is traffic information only for traffic congestion, the route may not be changed depending on the distance of the congestion.
·If there is no available avoidance route, the route may not be changed.
·Depending on provided data, the "From" and "To" information of the traffic event information may not be displayed.
·Provided data may differ from actual condition.
VEHICLE CUSTOMIZATION OUTLINE
Customization of functions can also be customized on the multi-display assembly screen. Refer to Owner's Manual for further information on customizable items for the navigation system.
- HINT:
- ·
Items available for customization via the navigation system can also be customized by using the GTS.
·Some customize parameters displayed on the GTS will be displayed on the "Vehicle Customization" screen for the navigation system. Users can customize these items.
EXPORT / IMPORT MEMORY POINT FUNCTION OUTLINE
This function allows memory points stored in the multi-media module receiver assembly to be registered to another multi-media module receiver assembly.
Memory points stored in the multi-media module receiver assembly can be exported to a USB device. Data exported to a USB device can be imported to another multi-media module receiver assembly using a USB device.
CUSTOMIZE STARTUP IMAGE OR SCREEN OFF IMAGE FUNCTION OUTLINE
An image can be copied from a USB device. The image can be used as the startup image or screen off image of the navigation system.
DIAGNOSTIC FUNCTION OUTLINE
The navigation system has a diagnostic function (the result is indicated on the master unit).
COMMUNICATION SYSTEM
MOST Network Outline
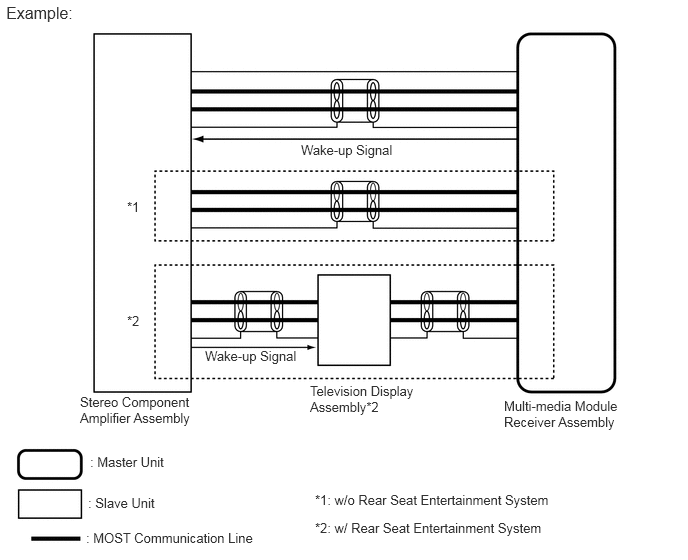
Navigation system components communicate with each other via the MOST network.
The MOST network uses a shielded twisted pair of wires for its communication lines.
The master unit of the MOST network is the multi-media module receiver assembly.
MOST communication lines connect each slave unit centering around the master unit to form a MOST network ring.
The master unit sends a wake-up signal to activate each slave unit connected to the MOST network.
- HINT:
-
If a short or open circuit occurs in the MOST circuit, communication will be interrupted and the system will not operate normally.
AVC-LAN Outline
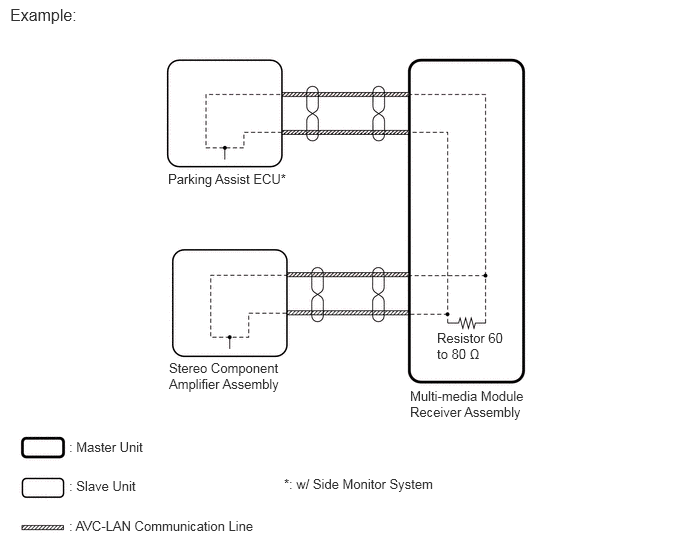
Components of the navigation system communicate with each other via the AVC-LAN.
The AVC-LAN uses a twisted pair of wires for its communication lines.
The master unit of the AVC-LAN is the multi-media module receiver assembly.
- HINT:
- ·
The multi-media module receiver assembly has the resistance (60 to 80 Ω) necessary for communication.
·If a short or open circuit occurs in the AVC-LAN circuit, communication is interrupted and the system will not operate normally.
Local Bus Outline
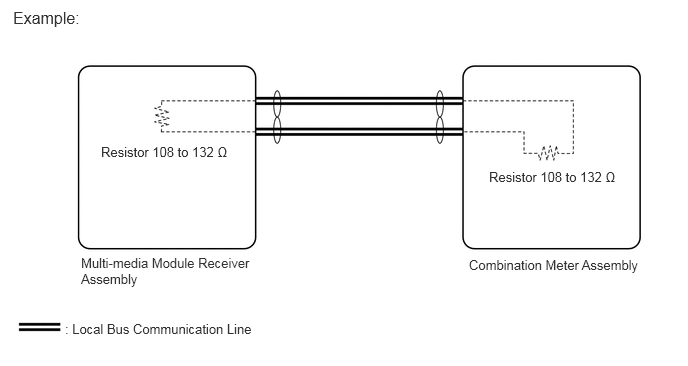
Components of the navigation system communicate with each other via the local bus.
The local bus uses a twisted pair of wires for its communication lines.
The master unit of the local bus is the multi-media module receiver assembly.
- HINT:
- ·
The multi-media module receiver assembly has the resistance (108 to 132 Ω) necessary for communication.
·If a short or open circuit occurs in the local bus circuit, communication is interrupted and the system will not operate normally.
CAN Communication Outline
The navigation system uses CAN communication between the multi-media module receiver assembly and ECUs.