BODY ELECTRICAL BLIND SPOT MONITOR SYSTEM GENERAL/CONTROL/DETAILS CONSTRUCTION AND OPERATION
BLIND SPOT MONITOR FUNCTION
The blind spot monitor function operates when both of the following conditions are met:
The blind spot monitor main switch is on.
The vehicle speed is greater than approximately 16 km/h (10 mph).
The blind spot monitor function can detect vehicles in its detection areas.
The detection areas formed by the blind spot monitor sensors LH and RH are as shown below:
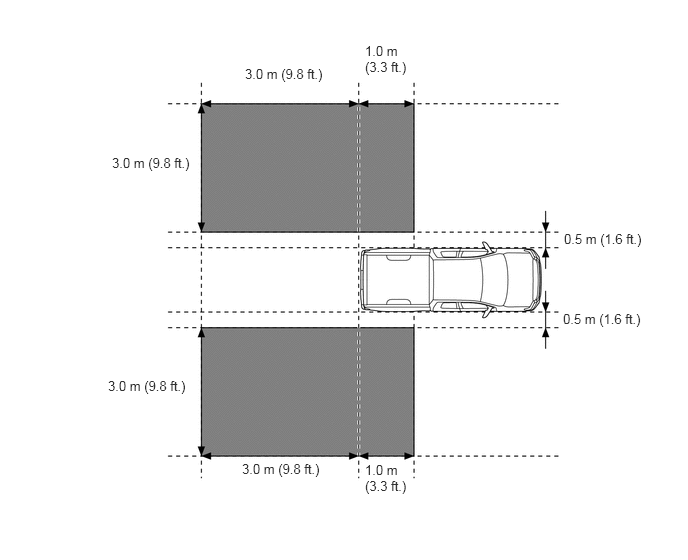
The following are examples of the operation of the function:
This vehicle is overtaken by another vehicle in the adjacent lane.
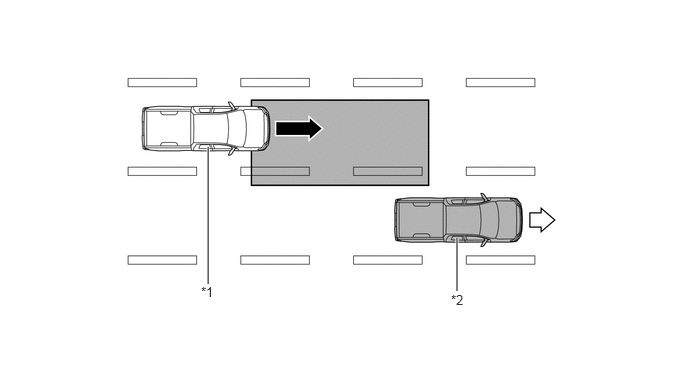
| *1 | Other Vehicle | *2 | This Vehicle |

|
Speed of this vehicle | 
|
Speed of other vehicle |

|
Blind spot detection area | - | - |
When another vehicle enters the detection area of this vehicle due to a lane change.
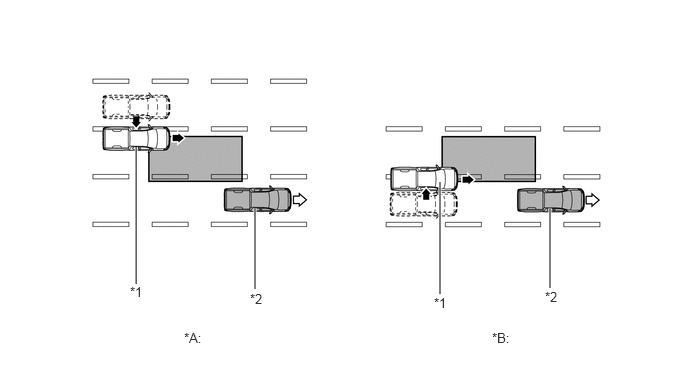
| *A | The other vehicle enters the detection area during lane change (merge in) (Type 1). | *B | The other vehicle enters the detection area during lane change (merge in) (Type 2). |
| *1 | Other Vehicle | *2 | This Vehicle |
|
|
Speed of this vehicle |
|
Speed of other vehicle |
|
|
Blind spot detection area | - | - |
REAR CROSS TRAFFIC ALERT FUNCTION
The rear cross traffic alert function operates when both of the following conditions are met:
The warning cancel switch is on.
Shift lever position is R.
The vehicle speed is 8km/h (5mph) or less.
The system continuously measures the relative speed of an approaching vehicle and its distance. If it is determined that the approaching vehicle will cross in the path of this vehicle, the Estimated Crossing Time (ECT) is calculated. When the ECT is 2.5 seconds or less, the system alerts the driver by flashing the outer rear view mirror indicator lights and sounding the rear cross traffic alert buzzer.
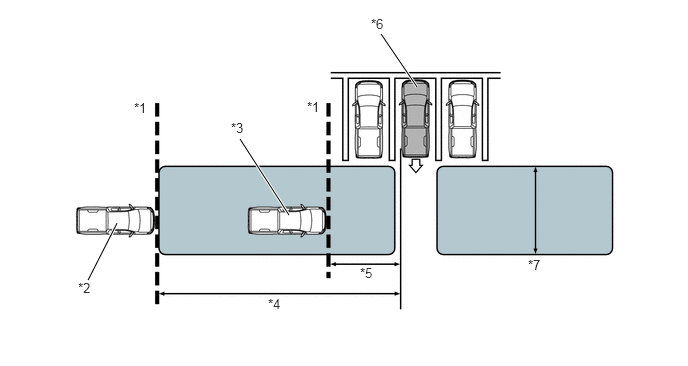
| *1 | Target Detection Line | *2 | Target Vehicle (Approximately 28 km/h (18 mph)) |
| *3 | Target Vehicle (Approximately 8 km/h (5 mph)) | *4 | Approximately 20 m (66 ft.) |
| *5 | Approximately 5.5 m (18.0 ft.) | *6 | This Vehicle |
| *7 | 6.0 m (19.7 ft.) | - | - |
|
|
Alert Area | - | - |
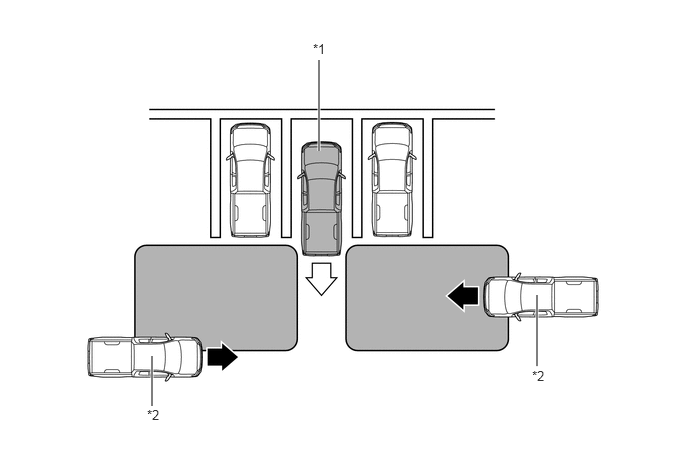
| *1 | This Vehicle | *2 | Target Vehicle |
|
|
Alert Area | - | - |
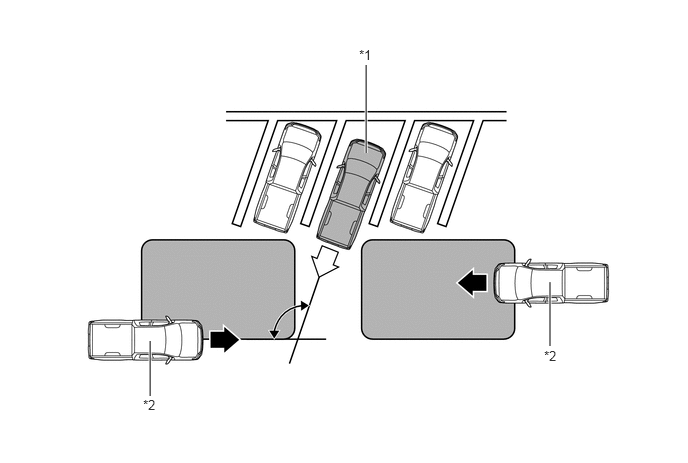
| *1 | This Vehicle | *2 | Target Vehicle |
|
|
Alert Area | - | - |
BLIND SPOT MONITOR SENSOR
The blind spot monitor sensor consists of a millimeter wave radar circuit and a signal processing circuit.
The millimeter wave radar uses frequencies in the 24 GHz band.
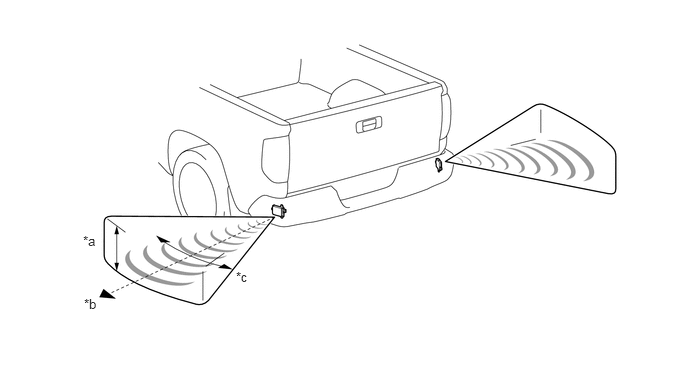
| *a | Approx. 20° | *b | Approx. 10 m (33 ft.) |
| *c | Approx. 150° | - | - |
The distance to the object, azimuth and relative speed are calculated from the information that is provided by the reflected millimeter wave radar as described below:
| Item | Calculation Method |
|---|---|
|
*: The Doppler effect causes the observer to perceive the radio waves emitted by a moving object to be a higher frequency as it approaches, and to be a lower frequency as it recedes. This phenomenon is created because when an object is located far away, the radio waves are perceived at higher frequencies than those of the radio source. An SST is used if radar axis confirmation is needed. For details, refer to the Repair Manual. |
|
| Distance | Calculated from the length of time that has elapsed from the time the waves of the millimeter wave radar have been emitted, until the reflected waves are received by the millimeter wave radar circuit. The distance is approx. 10 m (33 ft.). |
| Azimuth | Calculated from the reception angle of the millimeter wave radar reflections received. The detection angle has a horizontal range of approx. 150° and a vertical range of approx. 20°. |
| Relative Speed | Calculated by utilizing the change (Doppler effect*) that occurs in the frequency of the reflected millimeter wave radar waves. |
COMBINATION METER ASSEMBLY
Combination Meter Assembly
The combination meter assembly is provided with the multi-information display to inform the driver of a malfunction in the blind spot monitor system.
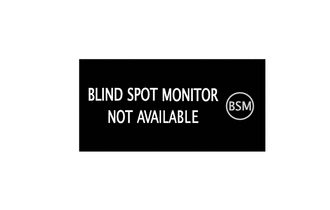
Two types of warning messages are used for the blind spot monitor system, as described below. The blind spot monitor system will not operate when these messages appear in the combination meter assembly.
| Multi-information Display | Detail |
|---|---|
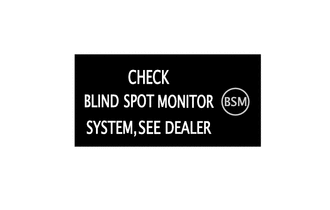
|
This message appears when the blind spot monitor sensor detects a system malfunction. |
|
This message appears when the blind spot monitor sensor determines the following conditions:
·
Dirty blind spot monitor sensor ·
Poor weather condition ·
Significantly high or low outside temperatures After these conditions have been eliminated, the system will operate normally. |