NETWORKING MULTIPLEX COMMUNICATION SYSTEM GENERAL/CONTROL/DETAILS GENERAL
OUTLINE
The multiplex communication system uses the 2 communication protocols (CAN and LIN) to achieve a streamlined wiring harness configuration.
| Protocol | Outline |
|---|---|
|
*: Models with Toyota safety sense |
|
| Controller Area Network (CAN) | The High Speed CAN (HS-CAN) is used for the power train, chassis and body electrical systems. The HS-CAN consists of the V bus and bus 2*. |
| Local Interconnect Network (LIN) | LIN is used for local area networking, in which the system has a respective bus for each body electrical system. |
There is no direct communication between CAN and LIN networks because these multiplex communication systems are incompatible. CAN and LIN are separate networks. Because these are separate networks, some ECUs serve as gateways to transfer of data, allowing communication between CAN and LIN networks.
MAIN FEATURES
Multiplex Communication
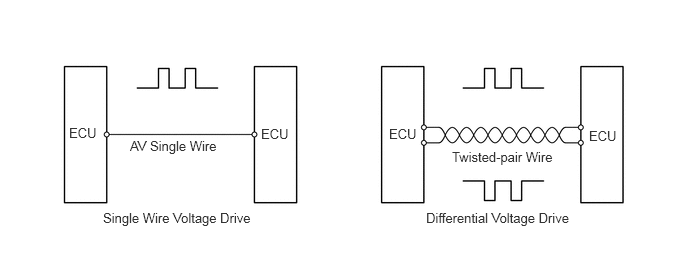
Generally speaking, multiplex communication refers to the use of serial communication data that consists of bits and frames in order to exchange information among various ECUs. This allows for a reduction of the amount of wiring on the vehicle. A bit is the basic unit of communication that is used to represent the information. A bit is represented by binary values of "0" or "1". For CAN communication, a differential voltage drive is used to represent the binary values of "0" or "1". This "Differential Voltage Drive" reduces the effects of electrical interference.
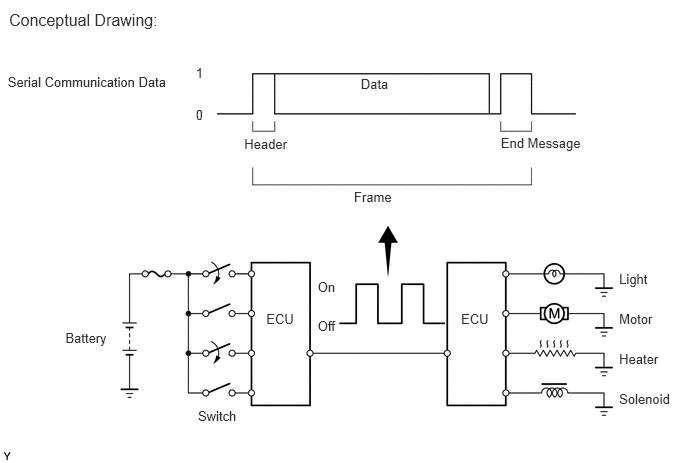
Differences between CAN and LIN
The protocols, which are the rules for establishing data communication, differ between the CAN and LIN. If the ECUs in the networks use different frameworks for their data, such as communication speed, communication wire and signals, they will be unable to understand each other. Therefore, protocols (rules) must be established among them.
Compared to the LIN, the CAN features high-speed data transmission. Therefore, the CAN is able to transmit larger amounts of data faster than other protocols. This feature makes it possible to transmit data accurately for the power train, chassis and body electrical systems, which requires large amounts of data to be transmitted in short periods of time.
| Protocol | CAN | LIN |
|---|---|---|
| Communication Speed | 500 kbps* | 9.6 kbps* |
| Communication Wire | Twisted-pair Wire | AV Single Wire |
| Drive Type | Differential Voltage Drive | Single Wire Voltage Drive |
| Data Length | 1-8 Byte (Variable) | 2, 4, 8 Byte (Variable) |
- HINT:
-
bps*: abbreviation for "Bits Per Second", indicating the number of bits that can be transmitted per second.
A twisted-pair wire is used for CAN communication. An Automobile Vinyl (AV) single wire is used for LIN communication.
| Communication Wire | Outline |
|---|---|
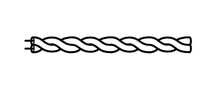
Twisted-pair Wire
|
This communication wire is a pair of twisted lines. Communication is driven by applying different voltages to the 2 lines in order to send a single signal. This system, which is called a "Differential Voltage Drive", reduces noise. |
AV Single Wire
|
This is a lightweight single communication wire that consists of a single core line surrounded by insulation. Voltage is applied to this line in order to drive communication, and this system is called a "Single Wire Voltage Drive". |