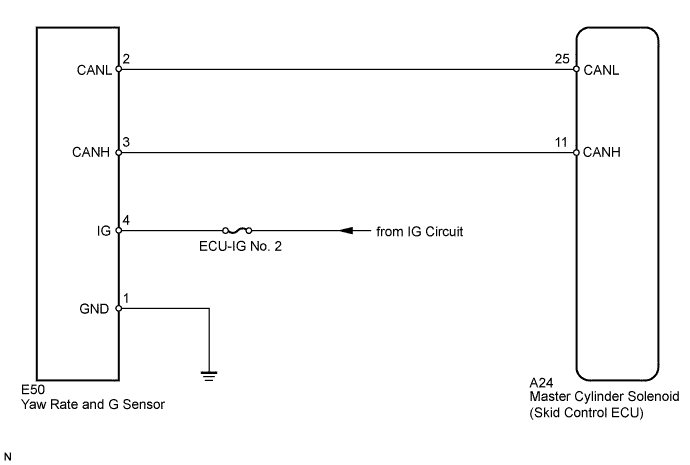
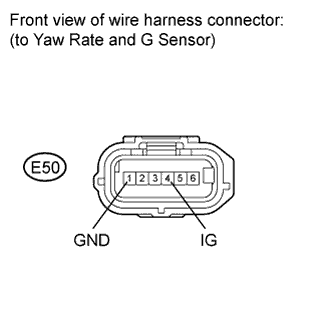
DTC Code
|
DTC Detection Condition
|
Trouble Area
|
C1232/32
|
At a vehicle speed of 10 km/h (6 mph) or more, the fluctuation range of the signal from one of either GL1 or GL2 is below 80 mV and the fluctuation range of the signal of the other is higher than 1.9 V for 30 seconds or more.
|
- Yaw rate and G sensor
- Harness or connector
- CAN communication system
|
C1234/34
|
A sensor malfunction signal is received from the yaw rate sensor.
|
- Yaw rate and G sensor
- Harness or connector
- CAN communication system
|
C1243/43
|
The following condition repeats 16 times.
- GL1 and GL2 do not change when the vehicle decelerates from 30 km/h (19 mph) to 0 km/h (0 mph).
|
- Yaw rate and G sensor
- Harness or connector
- CAN communication system
|
C1244/44
|
When either of the following conditions is detected:
1. Both of the following conditions continue for at least 60 seconds.
- The vehicle is stopped.
- The difference between GL1 and GL2 does not drop less than 0.4 G after it reaches 0.6 G or more.
2. A data malfunction signal is received from the G sensor.
|
- Yaw rate and G sensor
- Harness or connector
- CAN communication system
|
C1245/45
|
The following condition continues for at least 60 seconds.
- The difference between the values calculated from the G sensor value and vehicle speed exceeds 0.35 G.
|
- Yaw rate and G sensor
- Harness or connector
- CAN communication system
|
C1381/97
|
A G sensor power source malfunction signal is received for at least 10 seconds at a speed of more than 3 km/h (2 mph).
|
- Yaw rate and G sensor
- Harness or connector
- CAN communication system
|